recordVisual3d
Information
General
This element is implemented to allow 3d visualization using library Modelica3D.
Implementation
It uses declaration according to the Modelica3D library.
Notes
-
To use this library you must:
- Use and old version of OpenModelica that includes Modelica3D and Python file dbus-server.py. For example OpenModelica-1.9.0-RC1-revision-17414
- Remove or change the name of any library in Modelica directory that stars with ModelicaServices except for ModelicaServices 3.2.1 modelica3d.
- Follow the instructions of OpenModelica User's Guide section 11.1:
In order to run Modelica3D on windows you need following softwares; • Python – Install python from http://www.python.org/download/. Python2.7.3 is recommended. • PyGTK – Install GTK+ for python from http://ftp.gnome.org/pub/GNOME/binaries/win32/pygtk/2.24/. Download the all-in-one package. Recommmended is pygtk-all-in-one-2.24.2.win32-py2.7.msi. Run the Modelica3D server by executing the dbus-server.py script located at OPENMODELICAHOME/lib/omlibrary-modelica3d/osg-gtk. python dbus-server.py This will start the Modelica3D server and on success you should see the output, Running dbus-server... -
Uncomment the code in this class and save:
import ModelicaServices.Modelica3D;
inner ModelicaServices.Modelica3D.Controller m3d_control;
- Add the next code in your class and (with dbus_server.py opened) simulate.
extends Servomechanisms.Utilities.Visual3d;
- It is expected that in the future the 3d capability will be integrated in OpenModelica and this class would not be necessary.
Example
An example of usage with step input, inertial load and default parameters:
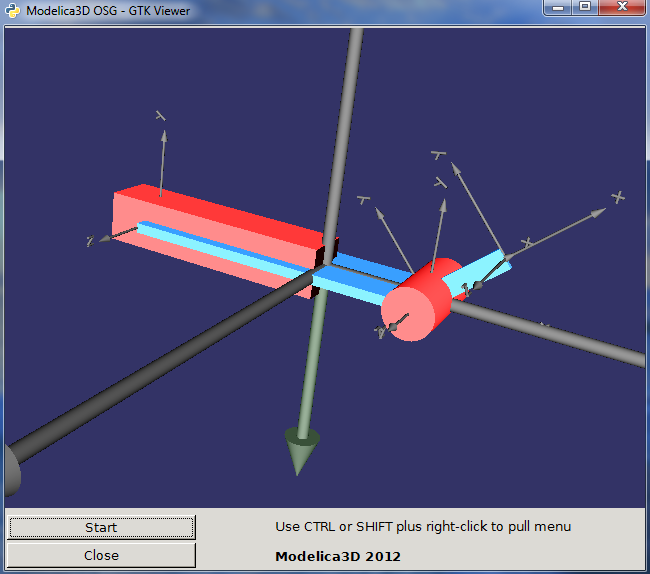
RR elbow down
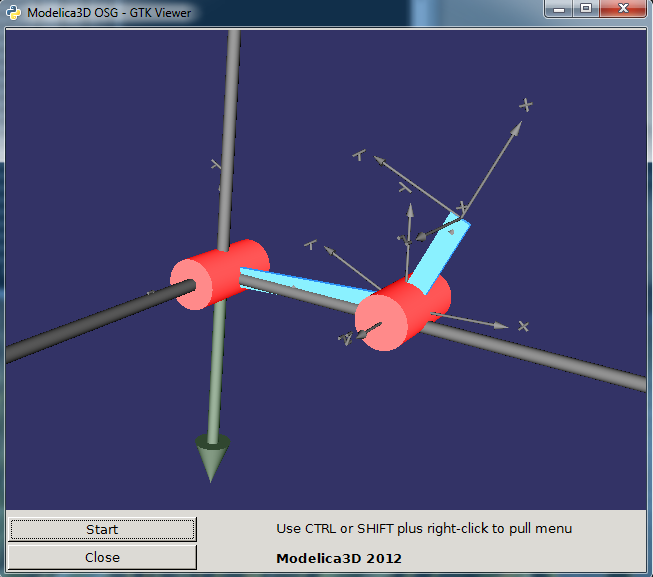
RR elbow up
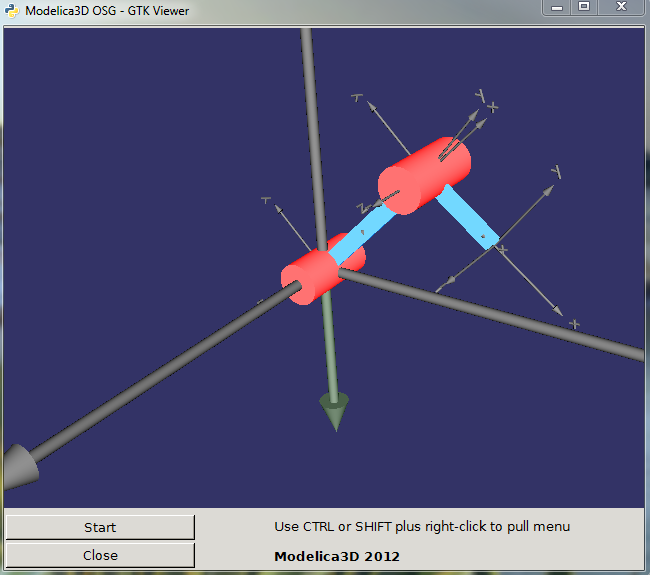
PR