modelDigitalPI
Extends from Modelica.Blocks.Interfaces.DiscreteBlock.
Information
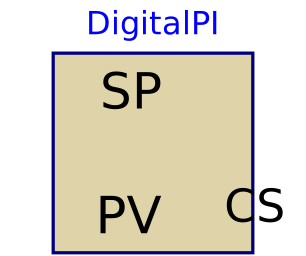
This is the model of a digital PI controller, complete with auto/man and tracking functionalies.
Parameters
| Type | Name | Default | Description |
|---|
| Real | Kp | | Gain |
| Modelica.SIunits.Time | Ti | | Integral time |
| Real | b | 1 | Set-point weight (proportional action) |
| Real | CSmax | | Control signal saturation upper bound |
| Real | CSmin | | Control signal saturation lower bound |
| Real | CSstart | 0 | Control signal start value |
| Boolean | StartSteadyState | false | True=steady state initial equations activated |
| SI.Time | Ts | samplePeriod | Sampling Time |
Components
| Type | Name | Default | Description |
|---|
| Real | e | | Sampled error signal |
| Real | e_int | | Integrated error |
| Real | e_int_wind | | Integrated error before anti-windup filtering |
| Real | CSwind | | Control signal before anti-windup filtering |
| Modelica.Blocks.Interfaces.RealInput | SP | | |
| Modelica.Blocks.Interfaces.RealOutput | CS | | |
| Modelica.Blocks.Interfaces.RealInput | PV | | |