modelBatteryPrimaryBalancingController
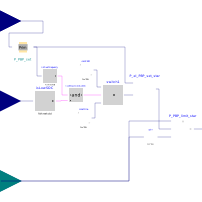
Extends from TransiEnt.Basics.Icons.Controller (Icon for controller).
Information
1. Purpose of model
Primary balancing controller that can be used for battery systems. The control is characterized by
- proportional behaviour (droop control)
- a frequency deadband
- a saturation block limiting the control setpoint to the available power reserve
- the option to increase setpoints by a constant gain when the storage capacity is low and the frequency control action requires a loading of the storage (overfrequency) in order to use the control action as a battery conditioing measure
2. Level of detail, physical effects considered, and physical insight
The control output is limited by the units reserved power which is passed to the model by a real input connector
while a frequency deadband is considered, there is no limit with respect to
- communication intervall or dynamic
- minimum increments of setpoints
3. Limits of validity
see above
4. Interfaces
delta_f: Is the deviation of frequency of its nominal value in Hz
P_el_pbp_band_set: Assigned primary balancing power bandwidth of unit (dtermined by pool controller) eqals maximum control power of unti
SOC: is the state of charge of the unit
P_el_pbp_set: Is the resulting setpoint for the controlled unit (zero if frequency equals nominal frequency)
5. Nomenclature
See interfaces.
6. Governing Equations
P_pbp = (f - f_n) / f_n / droop * P_pbp_max
7. Remarks for Usage
(no remarks)
8. Validation
Tested in check model "TransiEnt.Consumer.DemandSideManagement.PVBatteryPoolControl.Controller.Check.CheckBatteryPrimaryBalancingController"
9. References
(no remarks)
10. Version History
Model created by Pascal Dubucq (dubucq@tuhh.de) on 01.10.2014
Quality check (Code conventions) by Rebekka Denninger on 01.10.2016
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Real | k_loading | 1.2 | Gain of setpoint while loading (to balance energy losses) |
| Real | SOC_low | 0.5 | If SOC is below this threshold, the primary balancing setpoint can be increased using a gain factor (to prevent storage running empty) |
| SI.Frequency | delta_f_db | 0.01 | Frequency deadband of primary control |
| Real | delta_pr | 0.2 | droop of primary balancing control (delta_pr = delta_f / delta_P) |
| Real | P_n | Nominal power of primary control |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| TransiEnt.Basics.Interfaces.Electrical.ElectricPowerIn | P_el_pbp_band_set | Assigned primary balancing power bandwidth of unit (dtermined by pool controller) | |
| TransiEnt.Basics.Interfaces.General.FrequencyIn | delta_f | Connector of Real input signal | |
| TransiEnt.Basics.Interfaces.Electrical.ElectricPowerOut | P_el_pbp_set | Actual setpoint of frequency control | |
| Modelica.Blocks.Interfaces.RealInput | SOC | Connector of Real input signal 2 |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Producer.Electrical.Controllers.PrimaryBalancingControllerDeadband | P_PBP_set | ||
| Modelica.Blocks.Math.Product | P_el_PBP_set_star | ||
| Modelica.Blocks.Logical.And | loadRequestAndLowSOC | ||
| Modelica.Blocks.Sources.Constant | const120 | ||
| Modelica.Blocks.Logical.LessThreshold | isLowSOC | ||
| Modelica.Blocks.Logical.Switch | switch1 | ||
| Modelica.Blocks.Sources.Constant | constOne | ||
| Modelica.Blocks.Logical.GreaterThreshold | isOverFrequency | ||
| Modelica.Blocks.Nonlinear.VariableLimiter | P_PBP_limit_star | ||
| Modelica.Blocks.Math.Gain | gain |