modelPitchController_SI_dt_df
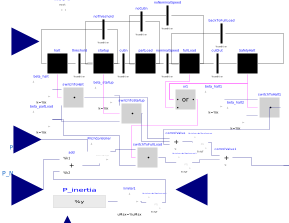
Extends from TransiEnt.Basics.Icons.Controller (Icon for controller).
Information
1. Purpose of model
Pitch Controller with synthetic Inertia control depending on the rate of change of frequency (df/dt).
2. Level of detail, physical effects considered, and physical insight
Quasistationary model for real power simulation only.
3. Limits of validity
(Purely technical component without physical modeling.)
4. Interfaces
beta_set: output for angle
u_s: Modelica RealInput
u_m: Modelica RealInput
der_f: input for frequency derivation
wind_fullload: input for velocity of wind in m/s
omeag_is: input for angular velocity in rad/s
5. Nomenclature
(no elements)
6. Governing Equations
(no equations)
7. Remarks for Usage
(no remarks)
8. Validation
Validated according to reference stated below.
9. References
Wu, Lei: "Towards an Assessment of Power System Frequency Support From Wind Pland - Modeling Aggregate Inertial Response"
10. Version History
Model created by Rebekka Denninger (rebekka.denninger@tuhh.de) on June 21 2016
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| TransiEnt.Producer.Electrical.Wind.Characteristics.VariableSpeed.WindSpeedOperationRanges | turbine | TransiEnt.Producer.Electrical.Wind.Characteristics.VariableSpeed.ExampleTurbineRanges() | |
| Real | k | 5e-5 | Gain of controller |
| SI.Time | Ti | 14 | Controller integral time constant |
| SI.Time | Td | 3.5 | Controller derivative time constant |
| Real | yMax | 30 | Upper limit of PI controlled beta setpoint |
| Real | yMin | 0 | Lower limit of output |
| Real | wp | 1 | Set-point weight for Proportional block (0..1) |
| Real | Ni | 0.9 | Ni*Ti is time constant of anti-windup compensation |
| Real | beta_start | Setpoint for pitch angle | |
| Real | v_wind_start | 0 | Setpoint to determine beta_start |
| Boolean | limitsAtInit | true | = false, if limits are ignored during initialization |
| Real | lambdaOpt | Optimal tip speed ratio | |
| Modelica.Units.SI.Density | rho | Density | |
| Modelica.Units.SI.Length | radius | Rotor Radius | |
| Real | cp_opt | Optimal capacity factor | |
| Real | J | Wind turbine moment ofinertia | |
| Real | P_el_n | Nominal electrical Power | |
| Modelica.Blocks.Types.SimpleController | controllerTypePitchCtrl | .Modelica.Blocks.Types.SimpleController.PID | Type of controller |
| Advanced | |||
| Boolean | strict | false | = true, if strict limits with noEvent(..) |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| TransiEnt.Basics.Interfaces.General.AngleOut | beta_set | ||
| Modelica.Blocks.Interfaces.RealInput | u_s | Connector of setpoint input signal | |
| Modelica.Blocks.Interfaces.RealInput | u_m | Connector of measurement input signal | |
| Modelica.Blocks.Interfaces.RealInput | der_f_grid | ||
| TransiEnt.Basics.Interfaces.General.AngularVelocityIn | omega_is | Connector of setpoint input signal | |
| TransiEnt.Basics.Interfaces.Ambient.VelocityIn | wind_fullLoad | Velocity of wind at full load |