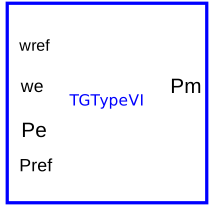
modelTGTypeVI
Hydro Turbine (Nonlinear model) and Governor (PID controller combined with servomotor)- control scheme Type 6
Information
Development level |
2 |
Reference |
Hydro Turbine (Linear model) and Governor (Standard model) - control scheme Type 6, PSAT Manual |
Last update |
2015-10-02 |
Author |
Tetiana Bogodorova, SmarTS Lab, KTH Royal Institute of Technology |
Contact |
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Real | gmax | Maximum gate opening (pu) | |
| Real | gmin | Minimum gate opening (pu) | |
| Real | vmax | Maximum gate opening rate (pu) | |
| Real | vmin | Minimum gate opening rate (pu) | |
| Real | Ta | Pilot valve time constant (s) | |
| Real | Tw | Water starting time (s) | |
| Real | beta | Transient speed droop (p.u./p.u.) | |
| Real | Kp | Proportional droop (p.u./p.u.) | |
| Real | Ki | Integral droop (p.u./p.u.) | |
| Real | Kd | Derivative droop (p.u./p.u.) | |
| Real | Td | Derivative droop time constant (s) | |
| Real | Rp | Permanent droop (p.u./p.u.) | |
| Real | Ka | ||
| Real | dref | ||
| Real | po |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Interfaces.RealOutput | Pm | Mechanical power (pu) | |
| Modelica.Blocks.Interfaces.RealInput | Pe | Active power (pu) | |
| Modelica.Blocks.Interfaces.RealInput | Pref | Active power reference (pu) | |
| Modelica.Blocks.Interfaces.RealInput | wref | Rotor speed reference (pu) | |
| Modelica.Blocks.Interfaces.RealInput | we | Rotor speed (pu) |
Components
Revisions
Copyright 2015-2016 RTE (France), SmarTS Lab (Sweden), AIA (Spain) and DTU (Denmark)
- RTE: http://www.rte-france.com
- SmarTS Lab, research group at KTH: https://www.kth.se/en
- AIA: http://www.aia.es/en/energy
- DTU: http://www.dtu.dk/english
The authors can be contacted by email: info@itesla-ipsl.org
This Source Code Form is subject to the terms of the Mozilla Public License, v. 2.0.
If a copy of the MPL was not distributed with this file, You can obtain one at http://mozilla.org/MPL/2.0.