modelPowerEuler
Power calculation comparison among three mover types, using Euler number computation for m_flow and dp
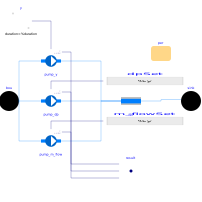
Extends from BuildingSystems.Fluid.Movers.Validation.PowerSimplified (Power calculation comparison among three mover types, using simplified power computation for m_flow and dp).
Information
This example is identical to
BuildingSystems.Fluid.Movers.Validation.PowerSimplified,
except that the efficiency of the flow controlled pumps
pump_dp and pump_m_flow
is estimated by using the Euler number and its correlation as implemented in
BuildingSystems.Fluid.Movers.BaseClasses.Euler.
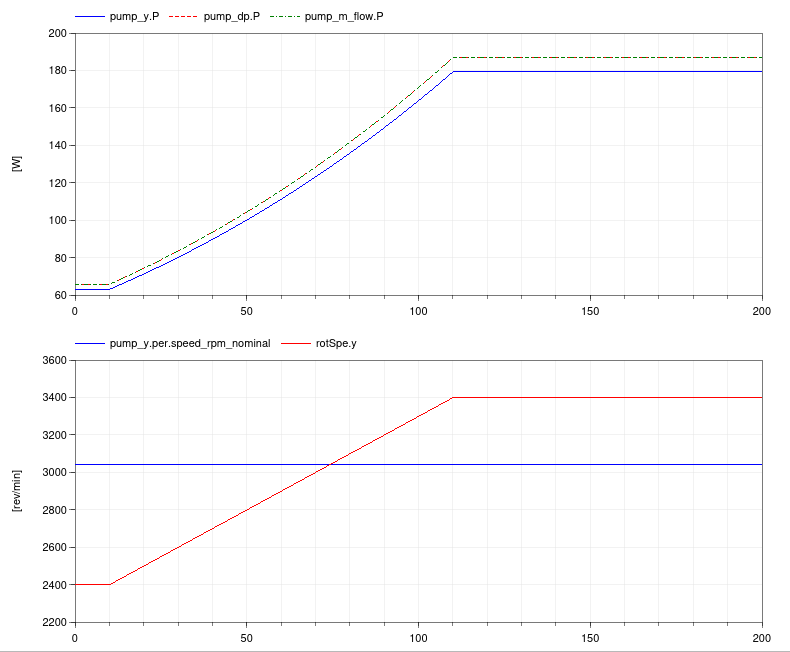
The figure below shows the approximation error for the power calculation where the speed y differs from the nominal speed ynominal.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Units.SI.MassFlowRate | m_flow_nominal (from PowerSimplified) | 3 | Nominal mass flow rate |
| BuildingSystems.Fluid.Movers.Data.Pumps.Wilo.Stratos30slash1to8 | per (from PowerSimplified) | Pump performance data | |
| BuildingSystems.Fluid.Movers.Data.Generic | perPea | Peak condition |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| BuildingSystems.Fluid.Movers.SpeedControlled_y | pump_y (from PowerSimplified) | Pump with normalised speed y as control signal | |
| BuildingSystems.Fluid.Movers.FlowControlled_dp | pump_dp (from PowerSimplified) | Pump with pressure rise as control signal | |
| BuildingSystems.Fluid.Movers.FlowControlled_m_flow | pump_m_flow (from PowerSimplified) | Pump with mass flow rate as control signal | |
| BuildingSystems.Fluid.Sources.Boundary_pT | bou (from PowerSimplified) | Pressure source | |
| BuildingSystems.Fluid.FixedResistances.PressureDrop | res (from PowerSimplified) | Flow resistance | |
| BuildingSystems.Fluid.Sources.Boundary_pT | sink (from PowerSimplified) | ||
| Modelica.Blocks.Sources.Ramp | y (from PowerSimplified) | Ramp for pump normalised speed control signal | |
| Modelica.Blocks.Sources.RealExpression | dpSet (from PowerSimplified) | Pressure rise across pump | |
| Modelica.Blocks.Sources.RealExpression | m_flowSet (from PowerSimplified) | Pump mass flow rate | |
| Modelica.Blocks.Routing.Multiplex3 | result (from PowerSimplified) |
Revisions
-
November 22, 2021, by Hongxiang Fu:
First implementation.