
modelLimPID
Test model for PID controller with optional reverse action
Extends from Modelica.Icons.Example (Icon for runnable examples).
Information
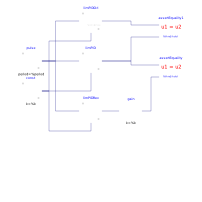
This model tests the implementation of the
PID controller with optional reverse action.
The model limPIDOri is the original
implementation of the controller from the Modelica
Standard Library. The models limPID
and limPIDRev are the implementations
from the Buildings library. The model
limPIDRev is parameterized to have
reverse action.
The assertion blocks test whether the results
of all three controllers are identical.
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Sources.Pulse | pulse | ||
| Buildings.Controls.Continuous.LimPID | limPID | ||
| Buildings.Controls.Continuous.LimPID | limPIDRev | Controller with reverse action | |
| Modelica.Blocks.Sources.Constant | const | ||
| Modelica.Blocks.Math.Gain | gain | ||
| Buildings.Utilities.Diagnostics.AssertEquality | assertEquality | ||
| Modelica.Blocks.Continuous.LimPID | limPIDOri | ||
| Buildings.Utilities.Diagnostics.AssertEquality | assertEquality1 |
Revisions
-
April 26, 2016, by Michael Wetter:
Relaxed tolerance of assertions from 1E-10 to 1E-3 as the default relative tolerance in JModelica is 1E-4. This is for Buildings, issue 510. -
November 21, 2011, by Michael Wetter:
Added documentation.