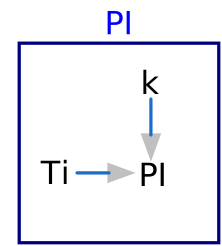
blockPI
Identify control gain and integral time of a PI controller
Information
This block calculates the control gain and the integral time of a PI controller.
Refer to the following blocks for detailed information:
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Buildings.Controls.OBC.CDL.Interfaces.RealInput | kp | Gain of a first-order plus time-delay (FOPTD) model | |
| Buildings.Controls.OBC.CDL.Interfaces.RealInput | T | Time constant of the FOPTD model | |
| Buildings.Controls.OBC.CDL.Interfaces.RealInput | L | Time delay of the FOPTD model | |
| Buildings.Controls.OBC.CDL.Interfaces.RealOutput | k | Control gain signal | |
| Buildings.Controls.OBC.CDL.Interfaces.RealOutput | Ti | Time constant signal for the integral term |
Revisions
-
June 1, 2022, by Sen Huang:
First implementation.