
modelPID
Test model for calculating parameters of a PID controller
Information
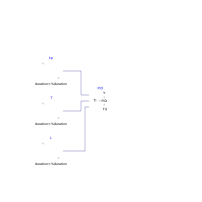
Validation test for the block Buildings.Controls.OBC.Utilities.PIDWithAutotuning.AutoTuner.AMIGO.PID.
The input kp varies from 1 to 2, input T varies from 0.5 to 1,
and input L varies from 0.3 to 0.6.
The control gain, the time constant of the integral term, and the time constant of the derivative term are calculated based on the equations shown in Buildings.Controls.OBC.Utilities.PIDWithAutotuning.SystemIdentification.AutoTuner.BaseClasses.AMIGO.PIDGain, Buildings.Controls.OBC.Utilities.PIDWithAutotuning.SystemIdentification.AutoTuner.AMIGO.BaseClasses.PIDIntegralTime, and Buildings.Controls.OBC.Utilities.PIDWithAutotuning.SystemIdentification.AutoTuner.AMIGO.BaseClasses.PIDDerivativeTime.
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Buildings.Controls.OBC.Utilities.PIDWithAutotuning.AutoTuner.AMIGO.PID | PID | Block that calculates the control gain, the integral time, and the derivative time | |
| Buildings.Controls.OBC.CDL.Reals.Sources.Ramp | kp | Gain of a first-order plus time-delay (FOPTD) model | |
| Buildings.Controls.OBC.CDL.Reals.Sources.Ramp | T | Time constant of the FOPTD model | |
| Buildings.Controls.OBC.CDL.Reals.Sources.Ramp | L | Time delay of the FOPTD model |
Revisions
-
June 1, 2022, by Sen Huang:
First implementation.