
modelReverseActingPIWithFirstOrderAMIGO
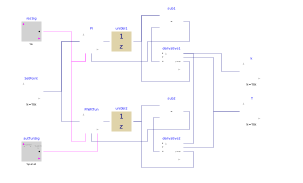
Test model for an autotuning reverse-acting PI controller
Information
Validation test for the block Buildings.Controls.OBC.Utilities.PIDWithAutotuning.FirstOrderAMIGO.
This example is similar as Buildings.Controls.OBC.Utilities.PIDWithAutotuning.Validation.ReverseActingPIDWithFirstOrderAMIGO. However, an autotuning PI controller rather than an autotuning PID controller is considered in this example.
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Buildings.Controls.OBC.CDL.Reals.Sources.Constant | SetPoint | Setpoint value | |
| Buildings.Controls.OBC.Utilities.PIDWithAutotuning.FirstOrderAMIGO | PIWitTun | PI controller with an autotuning feature | |
| Buildings.Controls.OBC.CDL.Reals.PIDWithReset | PI | PI controller with constant gains | |
| Buildings.Controls.OBC.CDL.Logical.Sources.Constant | resSig | Reset signal | |
| Buildings.Controls.OBC.CDL.Discrete.UnitDelay | uniDel1 | A delay process for control process 1 | |
| Buildings.Controls.OBC.CDL.Discrete.UnitDelay | uniDel2 | A delay process for control process 2 | |
| Buildings.Controls.OBC.CDL.Reals.Sources.Constant | k | Gain of the first order process | |
| Buildings.Controls.OBC.CDL.Reals.Sources.Constant | T | Time constant of the first order process | |
| Buildings.Controls.OBC.CDL.Reals.Subtract | sub1 | A subtract block that is used to mimic the first order process 1 | |
| Buildings.Controls.OBC.CDL.Reals.Subtract | sub2 | A subtract block that is used to mimic the first order process 2 | |
| Buildings.Controls.OBC.CDL.Reals.Derivative | derivative1 | A derivative block that is used to mimic the first order process 1 | |
| Buildings.Controls.OBC.CDL.Reals.Derivative | derivative2 | A derivative block that is used to mimic the first order process 2 | |
| Buildings.Controls.OBC.CDL.Logical.Sources.Pulse | autTunSig | Signal for enabling the autotuning |
Revisions
-
June 1, 2022, by Sen Huang:
First implementation.