blockTrimAndRespond
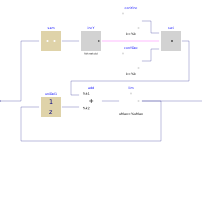
Trim and respond logic
Extends from Modelica.Blocks.Interfaces.DiscreteSISO (Single Input Single Output discrete control block).
Information
This model implements the trim and respond logic. The model samples the outputs of actuators every tSam.
The control sequence is as follows:
- If
u ≥ 0, then y = y + nActInc,
- If
u < 0, then y = y - yDec.
Parameters
| Type | Name | Default | Description |
|---|
| SI.Time | samplePeriod (from DiscreteBlock) | | Sample period of component |
| SI.Time | startTime (from DiscreteBlock) | 0 | First sample time instant |
| Real | uTri | | Value to triggering the request for actuator |
| Real | yEqu0 | | y setpoint when equipment starts |
| Real | yDec | | y decrement (must be negative) |
| Real | yInc | | y increment (must be positive) |
Contents
| Name | Description |
|---|
 UnitDelayprotected | |
 Samplerprotected | |
Revisions
-
September 24, 2015 by Michael Wetter:
Implemented UnitDelay and Sampler to avoid a translation warning
because these blocks do not set the fixed attribute of firstTrigger
in MSL 3.2.1.
-
December 5, 2012, by Michael Wetter:
Simplified implementation.
-
September 21, 2012, by Wangda Zuo:
Deleted the status input that was not needed for new control.
-
July 20, 2011, by Wangda Zuo:
Added comments, redefine variable names, and merged to library.
-
January 6 2011, by Michael Wetter and Wangda Zuo:
First implementation.