modelSimpleControlledDrive_virtualMeasurement
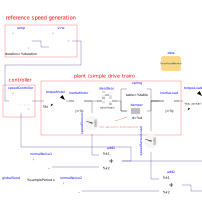
Drive train for virtual measurements

Extends from Modelica.Icons.Example (Icon for runnable examples), Credibility.Examples.SimpleControlledDriveNonlinear.PartialDrive (Not calibrated drive model with nonlinear compliance).

Information

A controlled simple drive train to generate noisy signals of speed sensors. The signals noisyMotorSpeed and noisyLoadSpeed can be used as virtual measurements for model calibration, whereby this example is configured in a way especially suitable for calibration of the damping parameter damper.d. Therefore, damper.d is set to its nominal value of 100 N·m·s/rad here, which is the value a successful calibration shall striver.

A suitable reference motor speed for calibration of this drive train configuration is prescribed by block sine which generates a sine sweep signal of constant amplitude. It is used as a reference value of the feedback controller which commands a motor torque for the drive train.

Parameters

TypeNameDefaultDescription
PartialDatadata (from PartialDrive)Data of the drive train, including credibility information
Units.SI.RotationalDampingConstantd_exact100Exact value of damping constant used for virtual measurement

Connectors

TypeNameDefaultDescription
Modelica.Blocks.Interfaces.RealOutputnoisyMotorSpeedConnector of Real output signal
Modelica.Blocks.Interfaces.RealOutputnoisyLoadSpeedConnector of Real output signal

Components

TypeNameDefaultDescription
Modelica.Mechanics.Rotational.Components.InertiainertiaMotor (from PartialDrive)J from datasheet; Init defined by system spec or scenario spec
Modelica.Mechanics.Rotational.Sources.TorquetorqueMotor (from PartialDrive)
Credibility.Examples.SimpleControlledDriveNonlinear.Utilities.SpringNonLinearspring (from PartialDrive)table from datasheet; Init defined by system spec or scenario spec
Modelica.Mechanics.Rotational.Components.Damperdamper (from PartialDrive)d to be calibrated; Init defined by system spec or scenario spec
Modelica.Mechanics.Rotational.Components.InertiainertiaLoad (from PartialDrive)Guess value, with defined uncertainty; Init defined by system spec or scenario spec
Modelica.Mechanics.Rotational.Sensors.SpeedSensorspeedSensor (from PartialDrive)
Modelica.Mechanics.Rotational.Components.IdealGearidealGear (from PartialDrive)
Modelica.Blocks.Continuous.LimPIDspeedControllerk, Ti, Ni: defined from control development, to be tested on control robustness ; yMax, yMin: from system spec; Init defined by optimization scenario spec
Modelica.Mechanics.Rotational.Sources.ConstantTorquetorqueLoadtau: guess value with uncertainty, could be dynamic load (boundary condition)
Modelica.Blocks.Sources.SineVariableFrequencyAndAmplitudesine
Modelica.Blocks.Sources.Rampramp
Modelica.Blocks.Noise.NormalNoisenormalNoise1
Modelica.Blocks.Math.Addadd1
Modelica.Blocks.Noise.NormalNoisenormalNoise2
Modelica.Blocks.Math.Addadd2
Modelica.Mechanics.Rotational.Sensors.SpeedSensorspeedSensorLoad
Modelica.Blocks.Noise.GlobalSeedglobalSeed