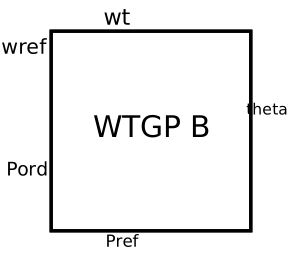
modelWTGPb
Extends from Dynawo.Electrical.Controls.WECC.Parameters.Mechanical.ParamsWTGPb, Dynawo.Electrical.Controls.WECC.Mechanical.BaseClasses.BaseWTGP (Base Pitch Controller).
Information
This block contains the Pitch controller model Type B for a WindTurbineGenerator Type 3 based on
https://www.wecc.org/Reliability/WECC-Second-Generation-Wind-Turbine-Models-012314.pdf
The Pitch Controller is designed to regulate blade pitch angle, ensuring optimal performance and protection under varying wind conditions. It serves the following primary functions:
Protection against High Wind Speeds: The controller adjusts the blade pitch to reduce aerodynamic loading during high wind conditions, preventing potential mechanical damage or structural failure.
Energy Optimization: Under moderate to low wind conditions, the pitch angle is adjusted to maximize the turbine's energy capture by optimizing the angle of attack of the blades relative to the wind direction.
Power Output Control: The controller also regulates the turbine's power output, especially in higher wind speeds, by adjusting the blade pitch to prevent exceeding the turbine's rated power capacity. This helps ensure the generator operates within safe limits.
Low Wind Operation: In low wind conditions, the controller adjusts the blade pitch to ensure the turbine starts generating power efficiently, even at lower wind speeds.
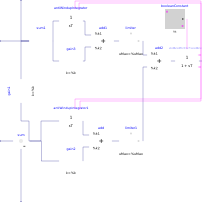
By tying together the limits of the controller’s various correctors, this model offers enhanced flexibility compared to the model A.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Types.ActivePowerPu | PConv0Pu (from ParamsWTGP) | Start value of active power at converter terminal in pu (generator convention) (base SNom) | |
| Types.AngleDegree | Theta0 (from ParamsWTGP) | 10 | Initial pitch angle in degree |
| Types.AngularVelocityPu | omegaRefWTGQ0Pu (from ParamsWTGP) | Start value of reference angular frequency of torque control in pu (base omegaNom) | |
| Pitch Control | |||
| Types.AngleDegree | ThetaWMax (from ParamsWTGPb) | Maximum pitch PI controller angle limit in degree | |
| Types.AngleDegree | ThetaWMin (from ParamsWTGPb) | Minimum pitch angle PI controller limit in degree | |
| Types.AngleDegree | ThetaCMax (from ParamsWTGPb) | Maximum pitch compensation PI controller angle limit in degree | |
| Types.AngleDegree | ThetaCMin (from ParamsWTGPb) | Minimum pitch compensation PI controller angle limit in degree | |
| Types.Frequency | Kiw (from ParamsWTGP) | Pitch controller integral gain | |
| Types.PerUnit | Kpw (from ParamsWTGP) | Pitch controller proportional gain | |
| Types.Frequency | Kic (from ParamsWTGP) | Pitch compensation integral gain | |
| Types.PerUnit | Kpc (from ParamsWTGP) | Pitch Compensation proportional gain | |
| Types.PerUnit | Kcc (from ParamsWTGP) | Proportionnal cross-compensation gain | |
| Types.Time | tTheta (from ParamsWTGP) | Pitch time constant in s | |
| Types.AngleDegree | ThetaMax (from ParamsWTGP) | Maximum pitch angle limit in degree | |
| Types.AngleDegree | ThetaMin (from ParamsWTGP) | Minimum pitch angle limit in degree | |
| Types.AngularVelocityDegree | ThetaRMax (from ParamsWTGP) | Maximum pitch angle rate limit in degree/s | |
| Types.AngularVelocityDegree | ThetaRMin (from ParamsWTGP) | Minimum pitch angle rate limit in degree/s | |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Interfaces.RealInput | POrdPu (from BaseWTGP) | Active power order in pu (base SNom) (generator convention) | |
| Modelica.Blocks.Interfaces.RealInput | PRefPu (from BaseWTGP) | Reference active power in pu (base SNom) (generator convention) | |
| Modelica.Blocks.Interfaces.RealInput | omegaRefWTGQPu (from BaseWTGP) | Reference angular frequency of torque control in pu (base omegaNom) | |
| Modelica.Blocks.Interfaces.RealInput | omegaTPu (from BaseWTGP) | Turbine frequency in pu (base omegaNom) | |
| Modelica.Blocks.Interfaces.RealOutput | theta (from BaseWTGP) | Pitch angle in degree |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Math.Feedback | sum (from BaseWTGP) | ||
| Modelica.Blocks.Math.Gain | gain1 (from BaseWTGP) | ||
| Modelica.Blocks.Math.Sum | sum1 (from BaseWTGP) | ||
| Modelica.Blocks.Math.Gain | gain2 (from BaseWTGP) | ||
| Modelica.Blocks.Math.Add | add (from BaseWTGP) | ||
| Modelica.Blocks.Math.Gain | gain3 (from BaseWTGP) | ||
| Modelica.Blocks.Math.Add | add1 (from BaseWTGP) | ||
| Modelica.Blocks.Nonlinear.Limiter | limiter (from BaseWTGP) | ||
| Modelica.Blocks.Nonlinear.Limiter | limiter1 (from BaseWTGP) | ||
| Modelica.Blocks.Math.Add | add2 (from BaseWTGP) | ||
| Modelica.Blocks.Sources.BooleanConstant | booleanConstant (from BaseWTGP) | ||
| Dynawo.NonElectrical.Blocks.Continuous.AntiWindupIntegrator | antiWindupIntegrator | ||
| Dynawo.NonElectrical.Blocks.Continuous.AntiWindupIntegrator | antiWindupIntegrator1 | ||
| Dynawo.NonElectrical.Blocks.Continuous.AbsLimRateLimFirstOrderFreezeLimDetection | absLimRateLimFirstOrderFreezeLimDetection |