modelPsdEcu2
Power Split hybrid power train controller, with SOC control, without ON/OFF
Extends from Partial.PartialEcu (Power Split hybrid power train controller, not using ON/OFF strategy).
Information
Second Electronic Control Unit of a Power Split Device (PSD) hybrid power train. Details on EHPTexamples tutorial.Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Real | genTorqueMax (from PartialEcu) | 80 | maximum absolute value of gen torque (Nm) |
| Real | maxTorqueReq (from PartialEcu) | 80 | Torque request (Nm) that corresponds to 1 from driver |
| Real | powFiltT (from PartialEcu) | 60 | Power filter time constant (s) |
| Real | genLoopGain (from PartialEcu) | 0.1 | Control gain between ice speed error and gen torque: Nm/(rad/s) |
| Real | socRef | 0.6 | Target value of SOC |
| Modelica.Units.SI.Power | socLoopGain | 10000 | soc loop gain |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| SupportModels.ConnectorRelated.Conn | conn (from PartialEcu) | ||
| Modelica.Blocks.Interfaces.RealInput | tauRef (from PartialEcu) |
Components
| Type | Name | Default | Description |
|---|---|---|---|
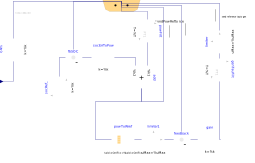
| Modelica.Blocks.Continuous.FirstOrder | powFilt (from PartialEcu) | ||
| Modelica.Blocks.Math.Gain | gain (from PartialEcu) | ||
| Modelica.Blocks.Math.Feedback | feedback (from PartialEcu) | ||
| Modelica.Blocks.Nonlinear.Limiter | limiter (from PartialEcu) | ||
| Modelica.Blocks.Tables.CombiTable1Ds | powToWref (from PartialEcu) | optimal ice speed as a function of power | |
| Modelica.Blocks.Math.Gain | toNm (from PartialEcu) | converts p.u. torque request into Nm | |
| Modelica.Blocks.Nonlinear.Limiter | limiter1 (from PartialEcu) | ||
| Modelica.Blocks.Continuous.FirstOrder | genTauFilt (from PartialEcu) | ||
| Modelica.Blocks.Math.Feedback | fbSOC | ||
| Modelica.Blocks.Sources.Constant | socRef_ | ||
| Modelica.Blocks.Math.Gain | socErrToPow | ||
| Modelica.Blocks.Math.Add | add |