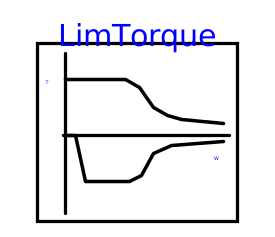
blockLimTorque
Information
Gives the maximum output torque as a function of the input speed.
There are two possibilities dependig on the value of limitsOnFile.
If limitsOnFile=false
When w<wMax the output is tauMax if tauMax*w<powMax, otherwise it is powMax/w
But if w is larger than powMax tauMax is rapidly falling to zero (reaches zero when speed overcomes wMax by 10%).
If limitsOnFile=true
maximum and minimum torques are taken from a txt file. Default interpaltion is with ontinuous derivative. No maxmimum speed is considered.
Torques and powers are in SI units
The simulation shows that up to 12 s and above 40s we are below baseSpeed and actual torque limit is maxTau; between 12 and 40s, we are under power limitation.
Suggested plots:
- OneFlange.variableLimter.limit1 with oneFlange.torque.tau, oneFlange.limTau.baseSpeed
- oneFlange.limTau.state
- oneflange.wMax and inertia.w.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | limitsOnFile | false | = true, if max torque is taken from a txt file |
| Modelica.Units.SI.Power | powMax | 50000 | Maximum mechanical power |
| Modelica.Units.SI.Torque | tauMax | 400 | Maximum torque |
| Modelica.Units.SI.AngularVelocity | wMax | 1500 | Maximum speed |
| String | limitsFileName | "noName" | File where matrix is stored |
| String | limitsTableName | "noName" | Name of the on-file maximum torque as a function of speed |
| Real | baseSpeed | powMax/wMax |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Interfaces.RealInput | w | ||
| Modelica.Blocks.Interfaces.RealOutput | yH | ||
| Modelica.Blocks.Interfaces.RealOutput | yL |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Integer | state | =0 below base speed; =1 before wMax; =2 in w limit, =3 above wMax | |
| Real | yHidealised | valore del limite di coppia in caso di curve idealizzate (T cost. sotto la velocità base, P cost. sopra) | |
| Modelica.Blocks.Tables.CombiTable1Ds | toMinMaxTq |