blockLimTorqueFV
Defines torque limits based on fixed max values of torque and power
Information
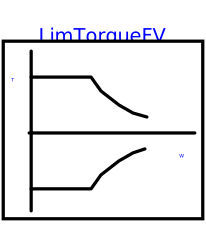
Gives the maximum output torque as a function of the input speed.
When w<wMax the output is tauMax if tauMax*w<powMax, othersise it is posMax/w. But if w is larger than wMax tauMax is rapidly falling to zero (reaches zero when speed overcomes wMax by 10%).
Torques and powers are in SI units.
Varable state determines the component's state as follows:
state=0 below base speed;
state=1 before wMax;
state=2 slightly above wMax (torque rapidly brought to zero)
state=3 above wMax, torque brought to zero;
So:
state= 0 or 1 if tauMax or powMax is delivered;
state =2 or 3 if w>wMax
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Units.SI.Power | powMax | 50000 | Maximum mechanical power |
| Modelica.Units.SI.Torque | tauMax | 400 | Maximum torque |
| Modelica.Units.SI.AngularVelocity | wMax | 1500 | Maximum speed |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Interfaces.RealInput | w | ||
| Modelica.Blocks.Interfaces.RealOutput | yH | ||
| Modelica.Blocks.Interfaces.RealOutput | yL |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Integer | state | =0 below base speed; =1 before wMax; =2 in w limit, =3 above wMax |