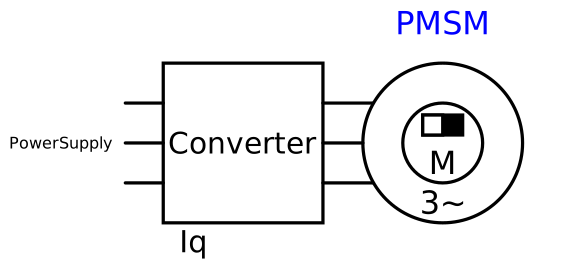
modelPMSM
Simple Model of a synchronous servo motor
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Engineering data | |||
| SI.Conversions.NonSIunits.AngularVelocity_rpm | n_n | Rated speed | |
| Integer | n_polePairs | Number of pole pairs | |
| SI.Torque | M_n | Rated torque (100 K) | |
| SI.Current | I_n | Rated current (100 K) | |
| SI.Torque | M_0_100 | Stall torque (100 K) | |
| SI.Current | I_0_100 | Stall current (100 K) | |
| SI.Torque | M_0_60 | Stall torque (60 K) | |
| SI.Current | I_0_60 | Stall current (60 K) | |
| SI.Inertia | J | Motor inertia | |
| Limiting data | |||
| SI.Conversions.NonSIunits.AngularVelocity_rpm | n_max | Max. permissible speed (mech.) | |
| SI.Torque | M_max | Maximum torque | |
| SI.Current | I_max | Maximum current | |
| SI.Temperature | T_max | 413.15 | Permissible temperature |
| SI.Voltage | U_eff_max | 380 | Voltage limit of motor module |
| Physical constants | |||
| SI.ElectricalTorqueConstant | k_T_0_100 | M_0_100/I_0_100 | Rated torque constant |
| SI.Resistance | R_ph_20 | Winding resistance at 20degC | |
| SI.Inductance | L_D | Rotating field inductance | |
| SI.Time | T_th | Thermal time constant | |
| Real | C_F | (T_ref_100/R_heat - Q_R_N)/SI.Conversions.from_rpm(n_n)^1.5 | Constant relating friction torque and square root of angular velocity |
| SI.Time | T_AT | 125e-6 | Sampling time for current control loop |
| Start conditions | |||
| SI.Temperature | T_start | Start temperature | |
| Safety factors | |||
| Real | S_n | 1 | Safety factor (>=1) for rotation speed (S_n * n <= n_max) |
| Real | S_M | 1 | Safety factor (>=1) for torque (S_n * M <= M_max) |
| Real | S_U | 1 | Safety factor (>=1) for voltage (S_n * u <= u_max) |
| Real | S_T | 1 | Safety factor (>=1) for temperature (S_n * T <= T_max) |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.Rotational.Interfaces.Flange_b | flange | Flange of shaft | |
| Modelica.Thermal.HeatTransfer.Interfaces.HeatPort_b | heatPort | ||
| Modelica.Blocks.Interfaces.RealInput | i_set |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Real | con_n_max | ||
| Real | con_M_max | ||
| Real | con_T_max | End of period value, for simulation of one period | |
| Real | con_U_max | ||
| Real | util_n_max | ||
| Real | util_M_max | ||
| Real | util_T_max | ||
| Real | util_U_max | ||
| Real | obj_rms_current | ||
| Real | obj_absMax_current | ||
| Real | obj_power_average | ||
| Components.Converter | converter | ||
| Components.MotorInductance | inductance | ||
| Components.MotorResistor | resistance | ||
| Components.EMF | airgap | ||
| Components.Friction | friction | ||
| Modelica.Mechanics.Rotational.Components.Fixed | fixed | ||
| RotationalComponents.Sensors.TorqueSensor | torqueSensor | ||
| Modelica.Thermal.HeatTransfer.Components.HeatCapacitor | heatCapacitor | ||
| Modelica.Thermal.HeatTransfer.Components.ThermalConductor | thermConductor | ||
| HelpBlocks.TemperatureSensor | tempSensor | ||
| Modelica.Mechanics.Rotational.Components.Inertia | motorInertia | ||
| RotationalComponents.Sensors.SpeedSensor_rpm | wSensor_rpm | ||
| Components.MotorCurrentSensor | currentSensor | ||
| Components.MotorVoltageSensor | voltageSensor | ||
| Components.MotorGround | motorGround | ||
| Modelica.Blocks.Continuous.PI | PI_I | Control according to amplitude optimum. k = Ts/(2*Ks*T_omega), where s denotes the controlled system with Ks = 1/R and T_omega = 1.5 * T_AT (sampling time) | |
| HelpBlocks.Feedback_mirror | I_feedback | ||
| Components.voltageLimit | voltageLimit | ||
| Modelica.Blocks.Nonlinear.Limiter | limiter | ||
| Modelica.Blocks.Continuous.FirstOrder | T_GI | 0,08 is just a guess value to avoid limits | |
| Modelica.Blocks.Math.Gain | gain |