modelPIDWithInputGains

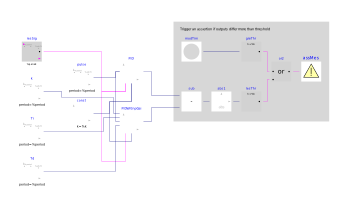
Test model for PIDWithInputGains
Information

Validation test for the block IDEAS.Controls.OBC.Utilities.PIDWithInputGains.

For t ∈ [0, 0.6] both PID controllers have the same gains. During this time, they generate the same output. Afterwards, the gains, and hence also their outputs, differ. IDEAS.Controls.OBC.CDL.Reals.PIDWithReset.

Components

TypeNameDefaultDescription
IDEAS.Controls.OBC.CDL.Reals.Sources.PulsepulseSetpoint
IDEAS.Controls.OBC.CDL.Reals.Sources.ConstantconstMeasured value
IDEAS.Controls.OBC.Utilities.PIDWithInputGainsPIDWitInpGaiPID controller with input gains
IDEAS.Controls.OBC.CDL.Reals.PIDWithResetPIDPID controller with constant gains
IDEAS.Controls.OBC.CDL.Logical.Sources.PulseresSigReset signal
IDEAS.Controls.OBC.CDL.Reals.Sources.PulsekControl gain signal
IDEAS.Controls.OBC.CDL.Reals.Sources.PulseTiTime constant signal for the integral term
IDEAS.Controls.OBC.CDL.Reals.Sources.PulseTdTime constant signal for the derivative term
IDEAS.Controls.OBC.CDL.Reals.Absabs1Absolute value of controller output
IDEAS.Controls.OBC.CDL.Reals.SubtractsubDifference in controller output
IDEAS.Controls.OBC.CDL.Reals.LessThresholdlesThrOutput true if outputs are bigger than threshold
IDEAS.Controls.OBC.CDL.Utilities.AssertassMesMake sure outputs are within expected tolerance
IDEAS.Controls.OBC.CDL.Reals.Sources.CivilTimemodTimCivil time
IDEAS.Controls.OBC.CDL.Reals.GreaterThresholdgreThrOutput true if model time is below 0.6
IDEAS.Controls.OBC.CDL.Logical.Oror2Output true either if time is bigger than 0.59, or if tolerance is maintained

Revisions

  • May 17, 2022, by Sen Huang:
    First implementation.