
modelCascadeAntiWindup
Extends from Modelica.Icons.Example (Icon for runnable examples).
Information
Description
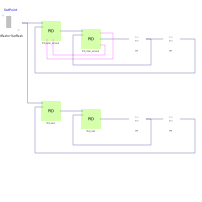
In this examples are compared two cascade control schemes: with and without external lock.
When two controllers are connected together in a cascade control scheme, the inner controller typically regulates the actuator, while
the outer one provides the Set Point reference for the inner one.
Since the inner controller acts on the plants, its Control Signal have to be limited, using AntiWindup. Unfortunately it is not possible for the outer
controller, to know the values for which the inner regulator saturates.
Such a problem can be voided by using the PID in its incremental form, using the Increment/Decrement lock feature, and creating
an external loop between the controllers.
If the inner regulator saturates, its satHi signal becomes true. Connecting this signal to the
forbidIncrement input of the outer controller, avoid an useless and potentially dangerous increase of its Control Signal ( that is the
Set point of the inner controller that saturated). With such a scheme a windup-like effect can be avoided.
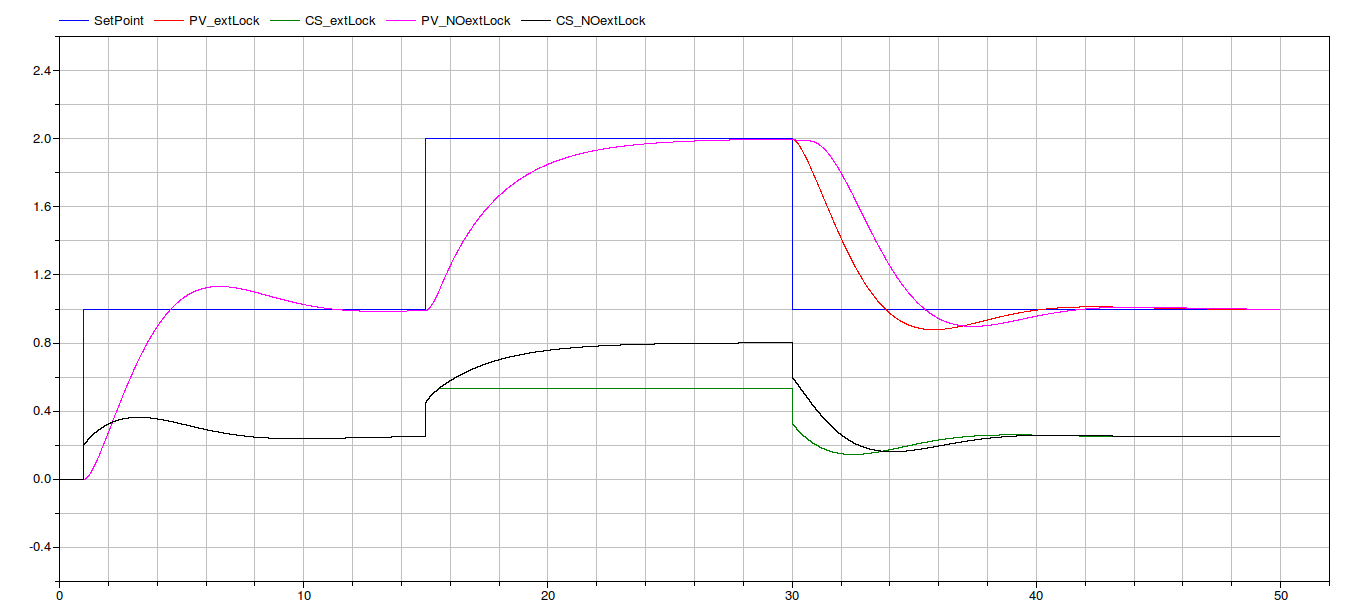
In the following figure, the green line is the CS of the outer controller with Increment/Decrement lock, while the black one is the output of the outer
controller whitout Increment/Decrement lock.
The black line shows a windup like effect that turns in a slower reaction when the Set Point changes at time t = 30.
Set Point, Process Variables (with and without external lock) and outer control signals (with and without external lock)
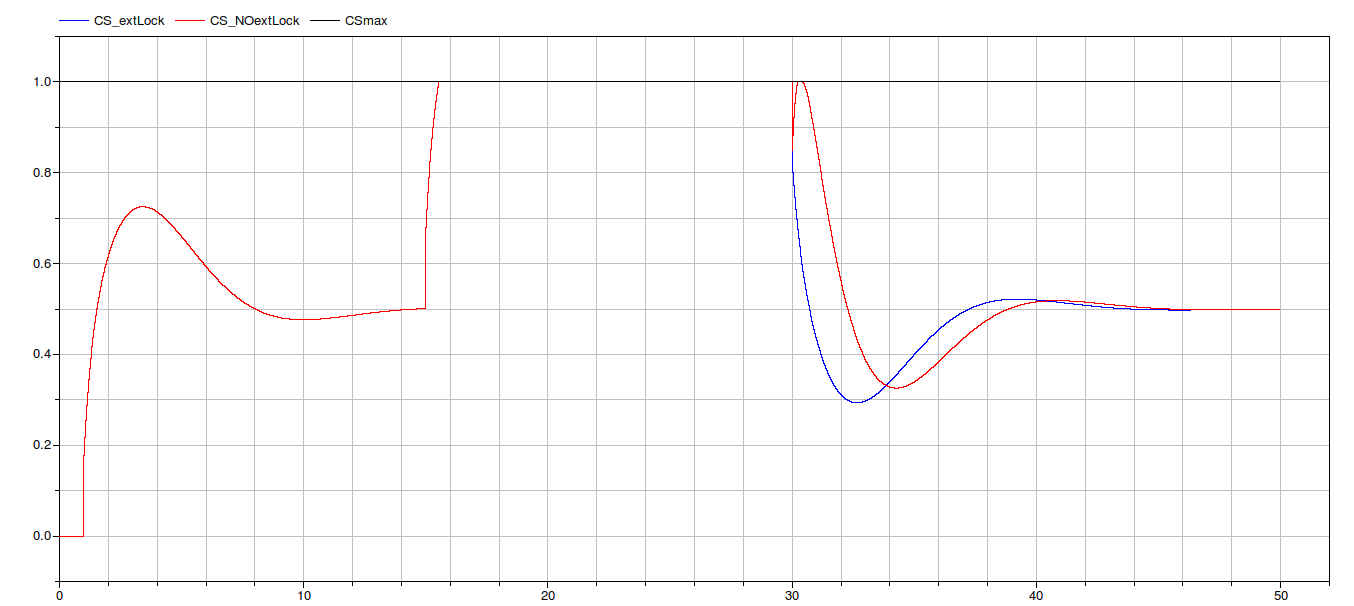
inner regulators Control Signal (with and without external lock)
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Controllers.Digital.PID_2dof | PID_outer_extLock | ||
| Controllers.Digital.PID_2dof | PID_inner_extLock | ||
| LinearSystems.Continuous.TransferFunction | P1 | inner process trasfer function | |
| LinearSystems.Continuous.TransferFunction | P2 | outer process trasfer function | |
| Modelica.Blocks.Sources.TimeTable | SetPoint | ||
| Controllers.Digital.PID_2dof | PID_outer | ||
| Controllers.Digital.PID_2dof | PID_inner | ||
| LinearSystems.Continuous.TransferFunction | P3 | inner process trasfer function | |
| LinearSystems.Continuous.TransferFunction | P4 | outer process trasfer function |
Revisions
- Industrial Control Systems (v 1.0.0) : April-May 2012
- List of revisions:
- 11 May 2012 (author: Marco Bonvini)
- Main Authors:
- Marco Bonvini; <bonvini@elet.polimi.it>
- Alberto Leva <leva@elet.polimi.it>
- Politecnico di Milano
- Dipartimento di Elettronica e Informazione
- Via Ponzio 34/5
- 20133 Milano - ITALIA -
- Copyright:
- Copyright © 2010-2012, Marco Bonvini and Alberto Leva.
- The IndustrialControlSystems package is free software; it can be redistributed and/or modified under the terms of the Modelica license.