
modelPI_ContinuousVsDigital
Comparison between continuous time PID and its discrete time implementations
Extends from Modelica.Icons.Example (Icon for runnable examples).
Information
Description
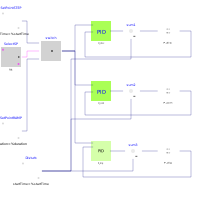
In this examples are compared three PID controllers:
- Continuous time PID with two degrees of freedom (model PID (with Ts=0) ),
- the discretised version of the continuous time PID with two degrees of freedom (model PID ),
- and the digital implementation of the PID with two degrees of freedom in the incremental form (model PID_2dof ).
There controllers regulates a second order process with trasfer function
   Y(s)          (1+15s)
   ----  =  ----------------
   U(s)       (1+10s)(1+2s)
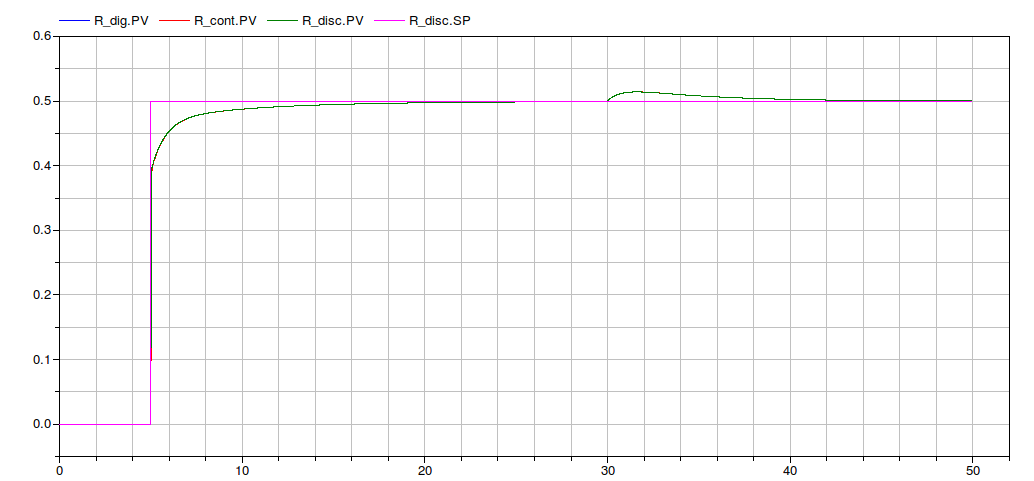
The following images show the SetPoint following and disturbance rejection without saturation
Set Point and Process Variables
Control Signals
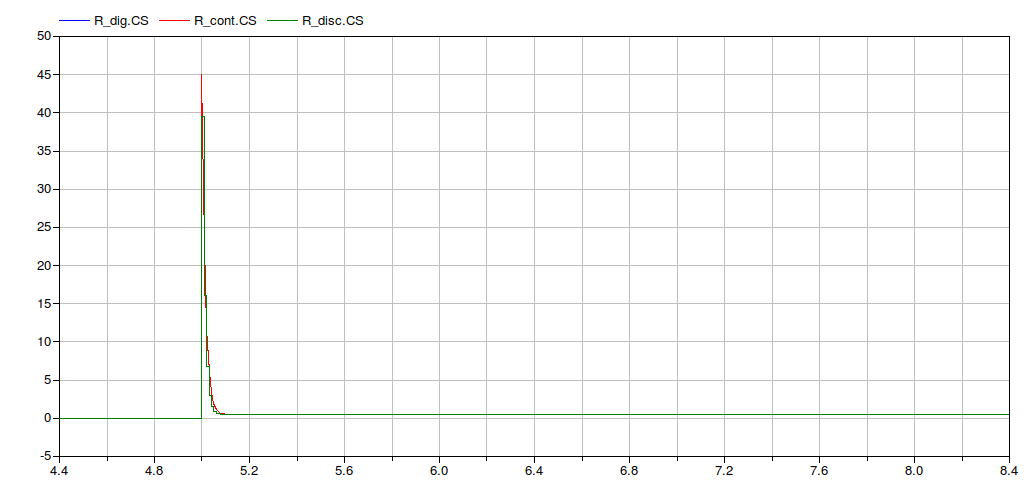
To be noticed that the discretised version of the PID and the digital implementation of the incremental PID have the same behaviour.
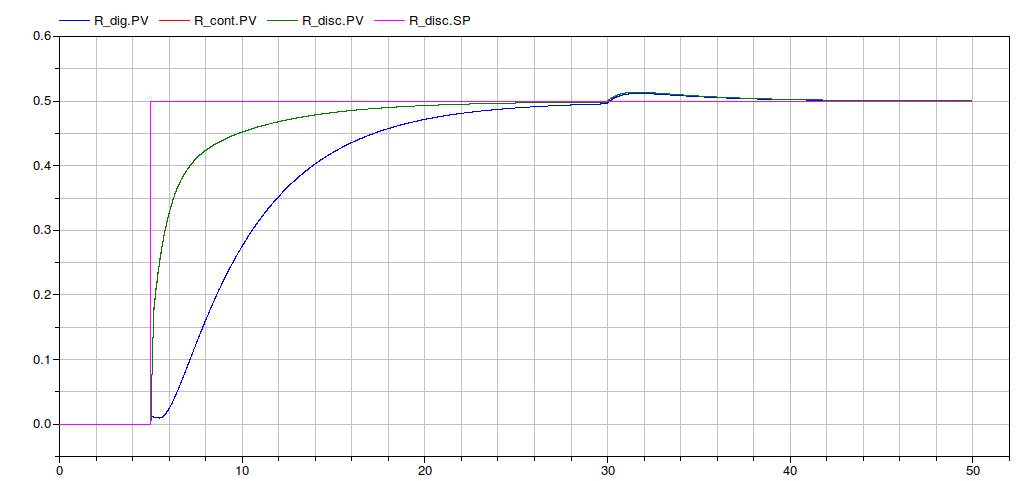
The same is not valid when the saturation is introduced. If limiting the controller action between [0,2] the discrete time version and the digital one behave quite differently
Set Point and Process Variables
Control Signals
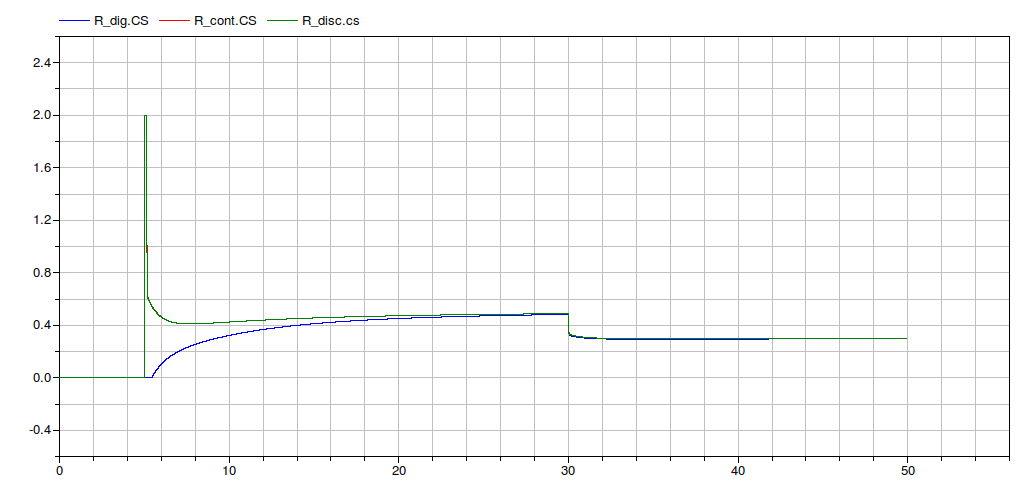
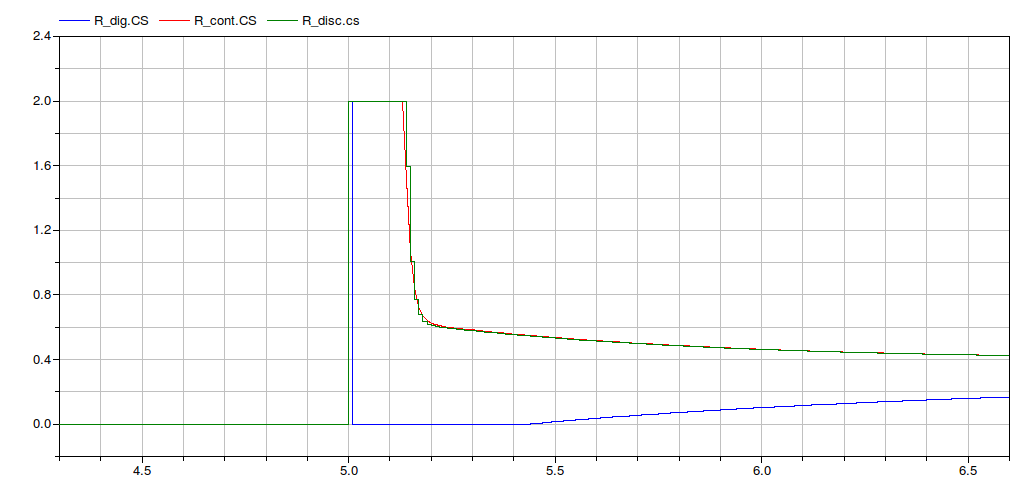
This difference is due to the nature of the digital implementation that is incremental, while the other two are positional.
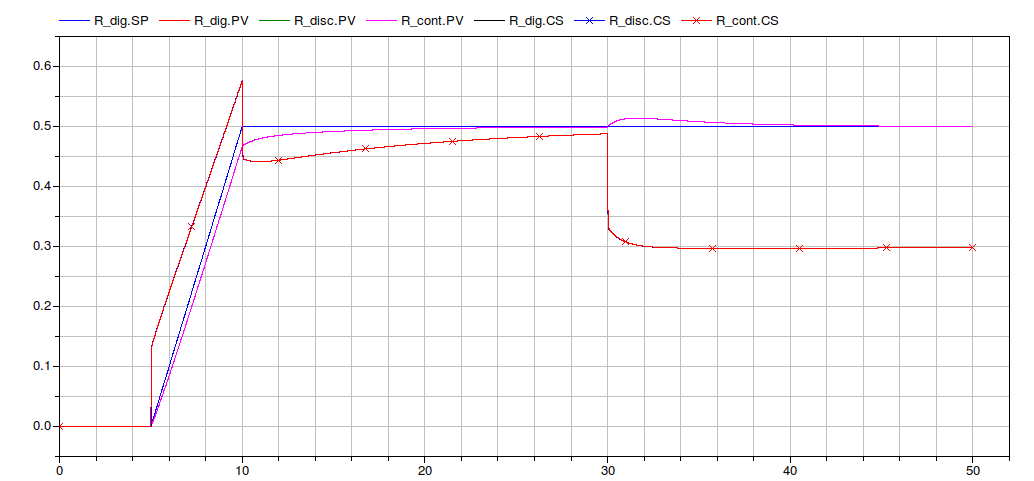
This problem does not appear if the Set Point reference changes soothly, switching to a ramp Set Point signal, as shown in the following picture.
Process Variables and Control Signals with a ramp Set Point
Components
| Type | Name | Default | Description |
|---|---|---|---|
| LinearSystems.Continuous.TransferFunction | P_disc | ||
| Controllers.PID | R_disc | ||
| Modelica.Blocks.Sources.Step | SetPointSTEP | ||
| Controllers.PID | R_cont | ||
| Modelica.Blocks.Math.Feedback | sum1 | ||
| Modelica.Blocks.Math.Feedback | sum2 | ||
| Modelica.Blocks.Sources.Step | Disturb | ||
| Modelica.Blocks.Math.Feedback | sum3 | ||
| Controllers.Digital.PID_2dof | R_dig | ||
| LinearSystems.Continuous.TransferFunction | P_cont | ||
| LinearSystems.Continuous.TransferFunction | P_dig | ||
| Modelica.Blocks.Sources.Ramp | SetPointRAMP | ||
| Modelica.Blocks.Logical.Switch | switch | ||
| Modelica.Blocks.Sources.BooleanConstant | SelectSP | if true the SP is a step, otherwise is a ramp |
Revisions
- Industrial Control Systems (v 1.0.0) : April-May 2012
- List of revisions:
- 11 May 2012 (author: Marco Bonvini)
- Main Authors:
- Marco Bonvini; <bonvini@elet.polimi.it>
- Alberto Leva <leva@elet.polimi.it>
- Politecnico di Milano
- Dipartimento di Elettronica e Informazione
- Via Ponzio 34/5
- 20133 Milano - ITALIA -
- Copyright:
- Copyright © 2010-2012, Marco Bonvini and Alberto Leva.
- The IndustrialControlSystems package is free software; it can be redistributed and/or modified under the terms of the Modelica license.