modelProcessControl
PID control of typical processes
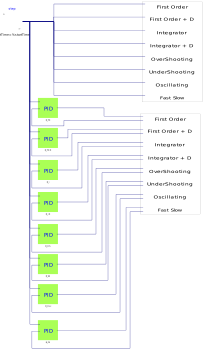
Extends from Modelica.Icons.Example (Icon for runnable examples).
Information
Description
In this examples the typical processes (contained in model
TypicalTF )
are controlled with PID regulators.
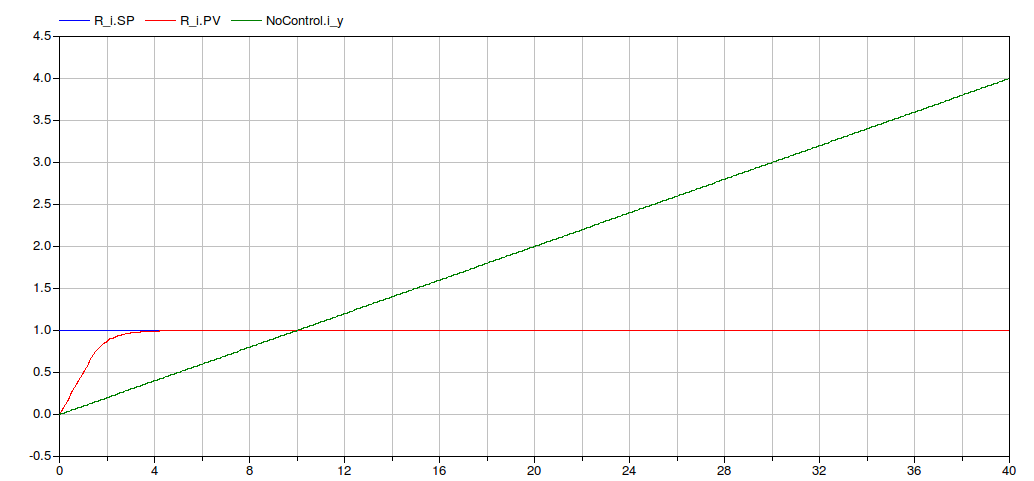
Process Trasfer function
| Integrator | |
|---|---|
Y(s) 1 ---- = ----- U(s) 5s |
Controller parameters
| Parameter | Value |
|---|---|
| Kp | 100 |
| Ti | 1 |
| Td | 0.1 |
| N | 10 |
| b | 1 |
| c | 1 |
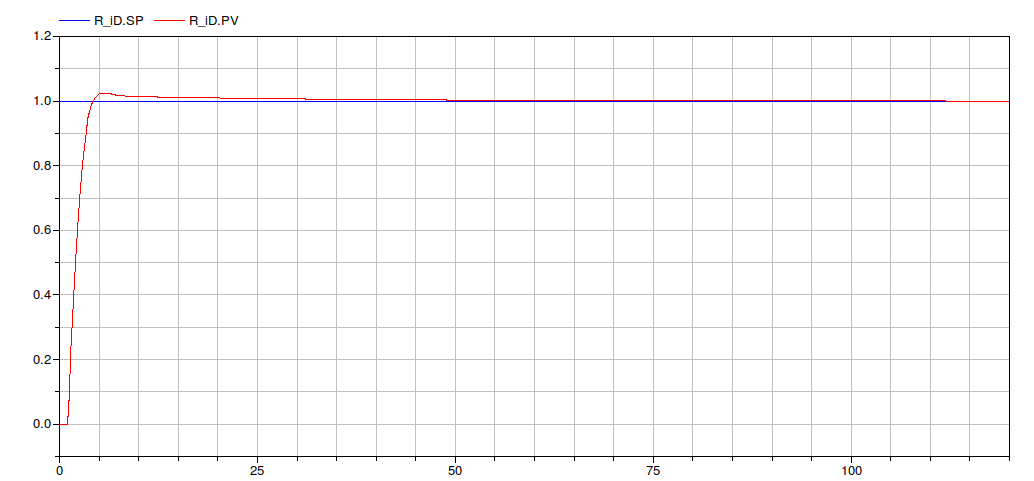
Process Trasfer function
| Integrator + delay | |
|---|---|
Y(s) 1 -1s ---- = ----- e U(s) 5s |
Controller parameters
| Parameter | Value |
|---|---|
| Kp | 5 |
| Ti | 30 |
| Td | 0.1 |
| N | 8 |
| b | 1 |
| c | 1 |
Process Trasfer function
| First Order | |
|---|---|
Y(s) 1 ---- = -------- U(s) 1 + 5s |
Controller parameters
| Parameter | Value |
|---|---|
| Kp | 10 |
| Ti | 3 |
| Td | 0.8 |
| N | 8 |
| b | 1 |
| c | 1 |
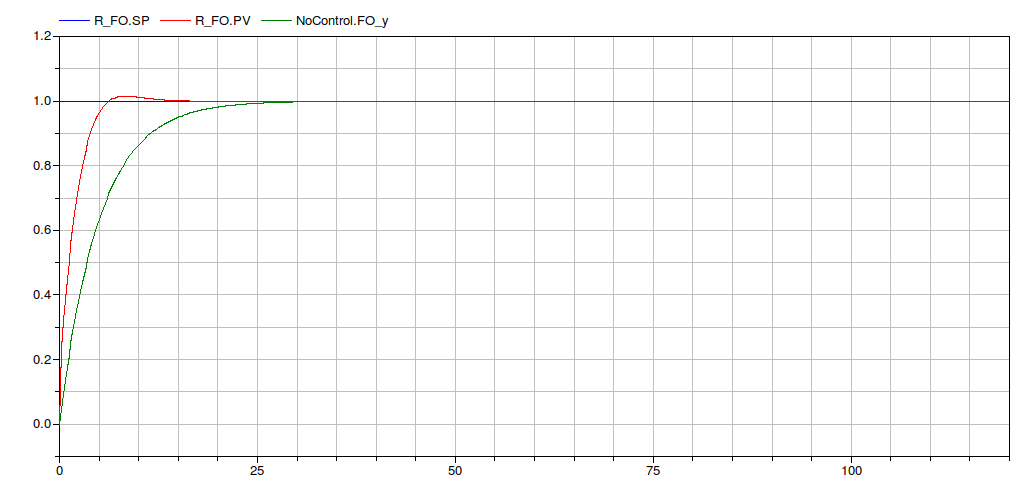
Process Trasfer function
| First Order + delay | |
|---|---|
Y(s) 1 -2s ---- = -------- e U(s) 1 + 5s |
Controller parameters
| Parameter | Value |
|---|---|
| Kp | 1 |
| Ti | 4 |
| Td | 0.2 |
| N | 5 |
| b | 1 |
| c | 1 |
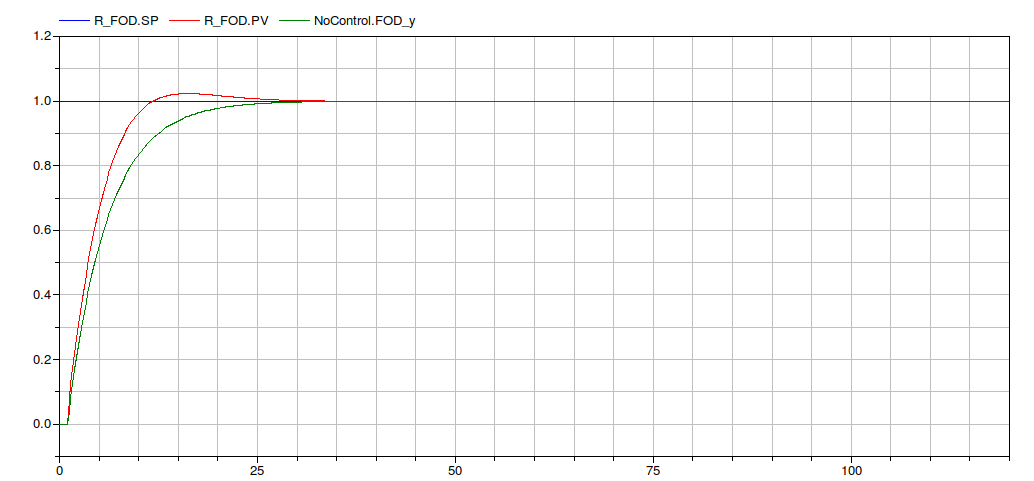
Process Trasfer function
| Fast Slow | |
|---|---|
Y(s) 1 + 5.8s ---- = -------------- U(s) (1 + 6s)(1+s) |
Controller parameters
| Parameter | Value |
|---|---|
| Kp | 5 |
| Ti | 0.8 |
| Td | 0.2 |
| N | 10 |
| b | 1 |
| c | 1 |
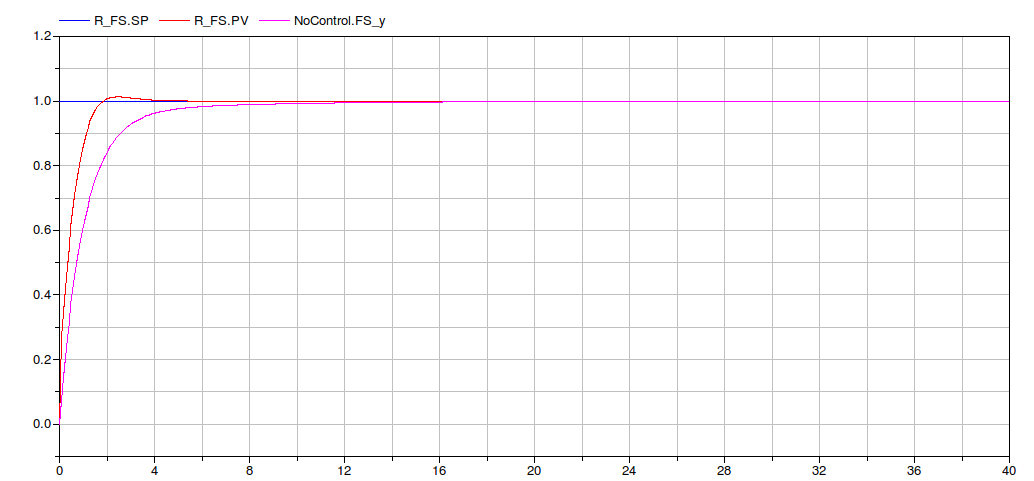
Process Trasfer function
| Overshooting | |
|---|---|
Y(s) 1 + 8s ---- = --------------- U(s) (1 + 5s)(1+2s) |
Controller parameters
| Parameter | Value |
|---|---|
| Kp | 5 |
| Ti | 2 |
| Td | 1 |
| N | 10 |
| b | 1 |
| c | 1 |
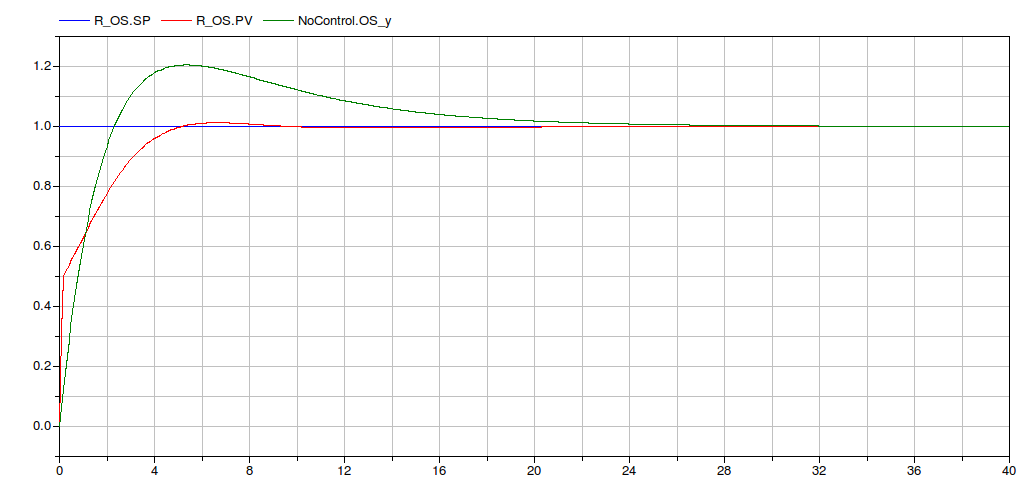
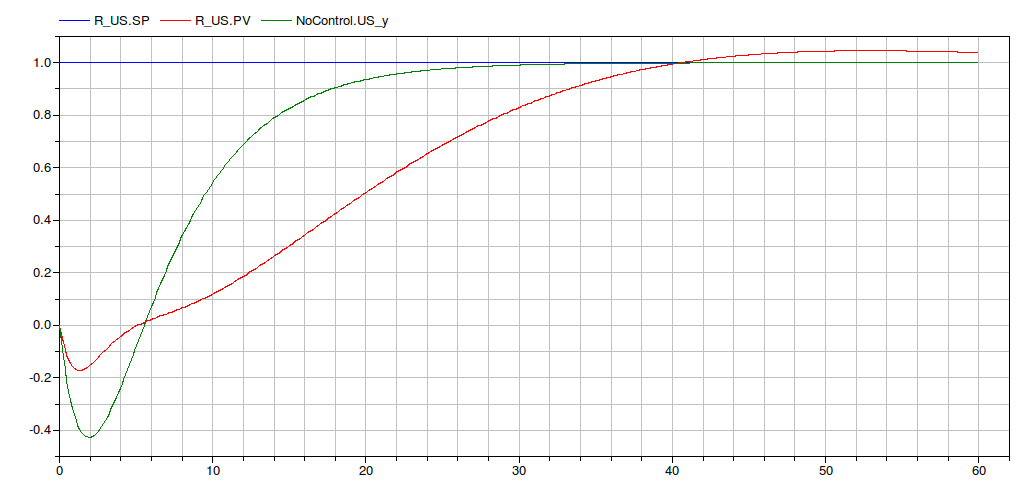
Process Trasfer function
| Undershooting | |
|---|---|
Y(s) 1 - 5.5s ---- = --------------- U(s) (1 + 5s)(1+2s) |
Controller parameters
| Parameter | Value |
|---|---|
| Kp | 0.1 |
| Ti | 2 |
| Td | 5 |
| N | 5 |
| b | 1 |
| c | 1 |
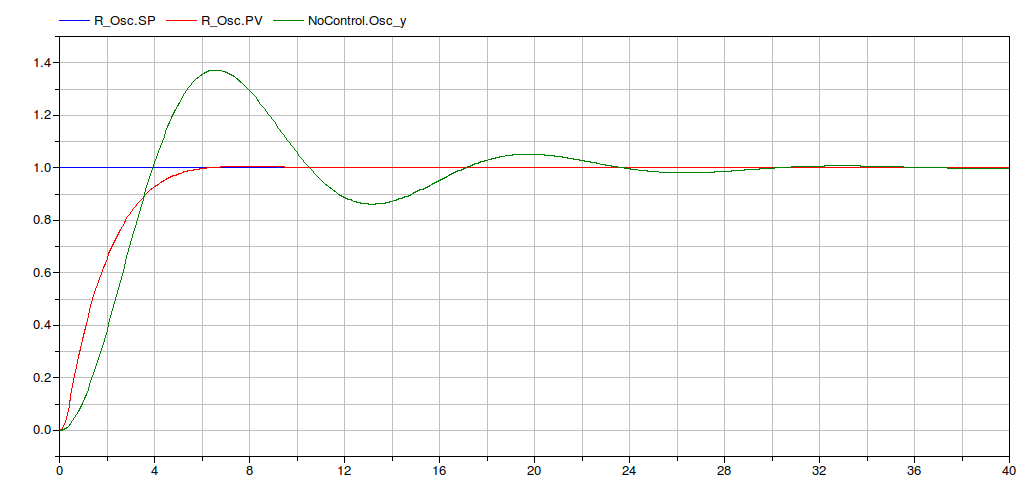
Process Trasfer function
| Complex Poles | |
|---|---|
Y(s) 1 ---- = -------------------- U(s) 1 + 1.2 s + 0.025s |
Controller parameters
| Parameter | Value |
|---|---|
| Kp | 10 |
| Ti | 2.5 |
| Td | 1 |
| N | 10 |
| b | 1 |
| c | 1 |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| IndustrialControlSystems.Applications.TrasferFunctions.TypicalTF | NoControl | ||
| Modelica.Blocks.Sources.Step | step | ||
| IndustrialControlSystems.Applications.TrasferFunctions.TypicalTF | Controlled | ||
| Controllers.PID | R_FO | ||
| Controllers.PID | R_FOD | ||
| Controllers.PID | R_i | ||
| Controllers.PID | R_iD | ||
| Controllers.PID | R_OS | ||
| Controllers.PID | R_US | ||
| Controllers.PID | R_Osc | ||
| Controllers.PID | R_FS |
Revisions
- Industrial Control Systems (v 1.0.0) : April-May 2012
- List of revisions:
- 11 May 2012 (author: Marco Bonvini)
- Main Authors:
- Marco Bonvini; <bonvini@elet.polimi.it>
- Alberto Leva <leva@elet.polimi.it>
- Politecnico di Milano
- Dipartimento di Elettronica e Informazione
- Via Ponzio 34/5
- 20133 Milano - ITALIA -
- Copyright:
- Copyright © 2010-2012, Marco Bonvini and Alberto Leva.
- The IndustrialControlSystems package is free software; it can be redistributed and/or modified under the terms of the Modelica license.