modelP
Proportional controller
Extends from Interfaces.Controller (Partial interface for a generic controller).
Information
Description
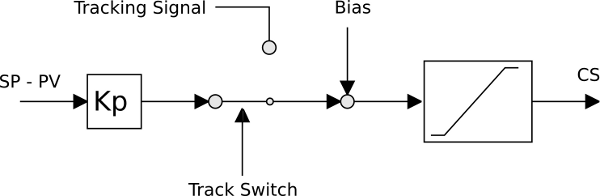
Proportional controller with Automatic, Tracking mode and bias signal.
The control law is defined as
CS(s) = Kp*(SP(s) - PV(s))
Scheme
| Name | Description | Conditional? |
|---|---|---|
| SP | Set Point | NO |
| PV | Process Variable | NO |
| CS | Control Signal | NO |
| TR | Track Reference signal | YES (useTS) |
| TS | Track Switch signal | YES (useTS) |
| Bias | Biasing signal | YES (useBIAS) |
| ATreq | AutoTuning request | YES (*) |
AutoTuning
The controller can have various operating conditions:
- Automatic,
- and Tracking
In the Automatic mode, the control output is computed with the proportional control law, while in the tracking mode
it is defined by the input TR.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Real | eps (from Controller) | 1e-1 | small time constant that represents the time for switching between auto and tracking mode |
| Boolean | useTS (from Controller) | false | =true, if TS and TR inputs are enabled |
| Boolean | useBIAS (from Controller) | false | =true, if BIAS input is enabled |
| Boolean | useAT (from Controller) | false | =true, if AutoTuning input is enabled |
| Boolean | useGS (from Controller) | false | =true, if GainScheduling inputs are enabled |
| Boolean | useSAT (from Controller) | false | =true, if Saturation outputs are enabled |
| Discretisation | |||
| Real | Ts (from Controller) | 0 | Sampling time (if <= 0 continuous time) |
| IndustrialControlSystems.LinearSystems.Discrete.Types.discrMethod | method (from Controller) | IndustrialControlSystems.LinearSystems.Discrete.Types.discrMethod.BE | Discretisation method |
| Saturation | |||
| Boolean | AntiWindup (from Controller) | false | Flag that enables the antiwindup feature |
| Real | CSmin (from Controller) | 0 | minimum value of the CS |
| Real | CSmax (from Controller) | 1 | maximum value of the CS |
| Initialisation | |||
| Real | CS_start (from Controller) | 0 | output initial value |
| Parameters | |||
| Real | Kp | 5 | Proportional gain |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Interfaces.RealInput | TR (from Controller) | Track Reference signal | |
| Modelica.Blocks.Interfaces.BooleanInput | TS (from Controller) | Track Switch signal | |
| Modelica.Blocks.Interfaces.RealInput | BIAS (from Controller) | Bias | |
| Modelica.Blocks.Interfaces.RealInput | SP (from Controller) | Set Point signal | |
| Modelica.Blocks.Interfaces.RealOutput | CS (from Controller) | Control signal | |
| Modelica.Blocks.Interfaces.RealInput | PV (from Controller) | Process Variable signal | |
| Modelica.Blocks.Interfaces.BooleanInput | ATreq (from Controller) | Auto Tuning request | |
| Modelica.Blocks.Interfaces.BooleanOutput | satHI (from Controller) | ||
| Modelica.Blocks.Interfaces.BooleanOutput | satLOW (from Controller) | ||
| Modelica.Blocks.Interfaces.RealInput | Kp_GS |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Real | bias (from Controller) | bias signal | |
| Real | tr (from Controller) | track reference value | |
| Boolean | ts (from Controller) | track reference signal | |
| Boolean | at_req (from Controller) | auto tuning enabling signal | |
| Boolean | satHigh (from Controller) | High saturation signal | |
| Boolean | satLow (from Controller) | Low saturation signal | |
| Real | Kp_act | Actual proportianal gain | |
| Real | Pout | output of the proportional block | |
| Real | satin | input of the saturation block |
Revisions
- Industrial Control Systems (v 1.0.0) : April-May 2012
- List of revisions:
- 11 May 2012 (author: Marco Bonvini)
- Main Authors:
- Marco Bonvini; <bonvini@elet.polimi.it>
- Alberto Leva <leva@elet.polimi.it>
- Politecnico di Milano
- Dipartimento di Elettronica e Informazione
- Via Ponzio 34/5
- 20133 Milano - ITALIA -
- Copyright:
- Copyright © 2010-2012, Marco Bonvini and Alberto Leva.
- The IndustrialControlSystems package is free software; it can be redistributed and/or modified under the terms of the Modelica license.