modelBasic
Comparison of the basic continuous and discrete time blocks
Extends from Modelica.Icons.Example (Icon for runnable examples).
Information
Description of the example
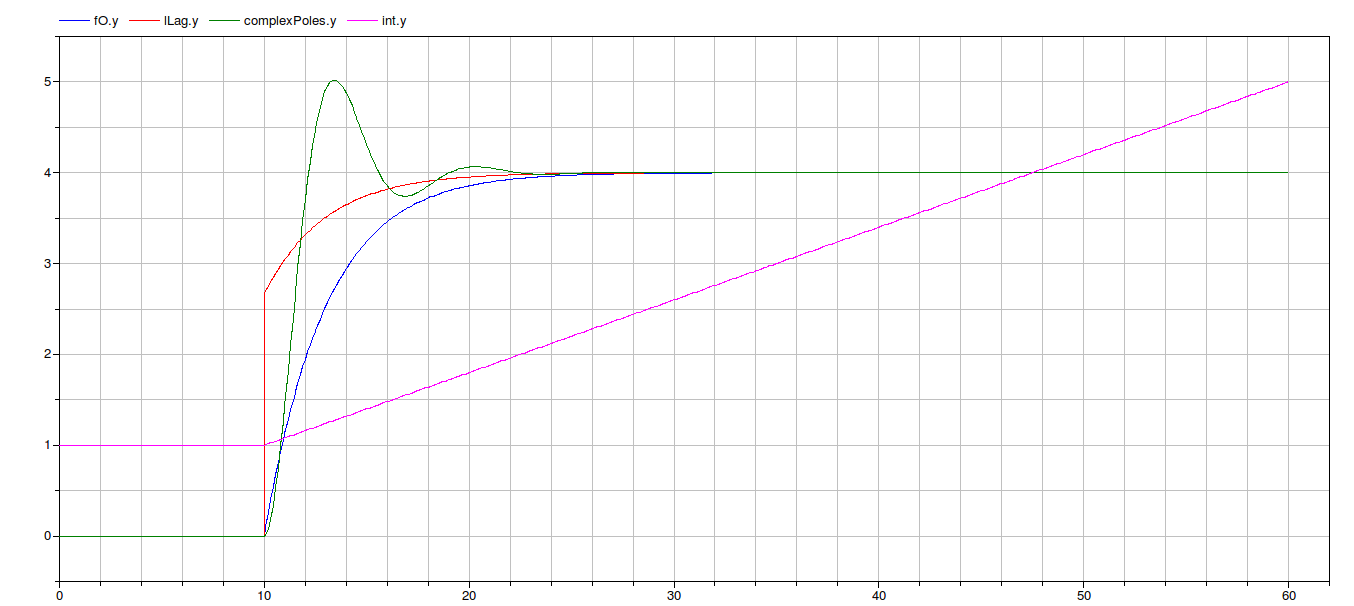
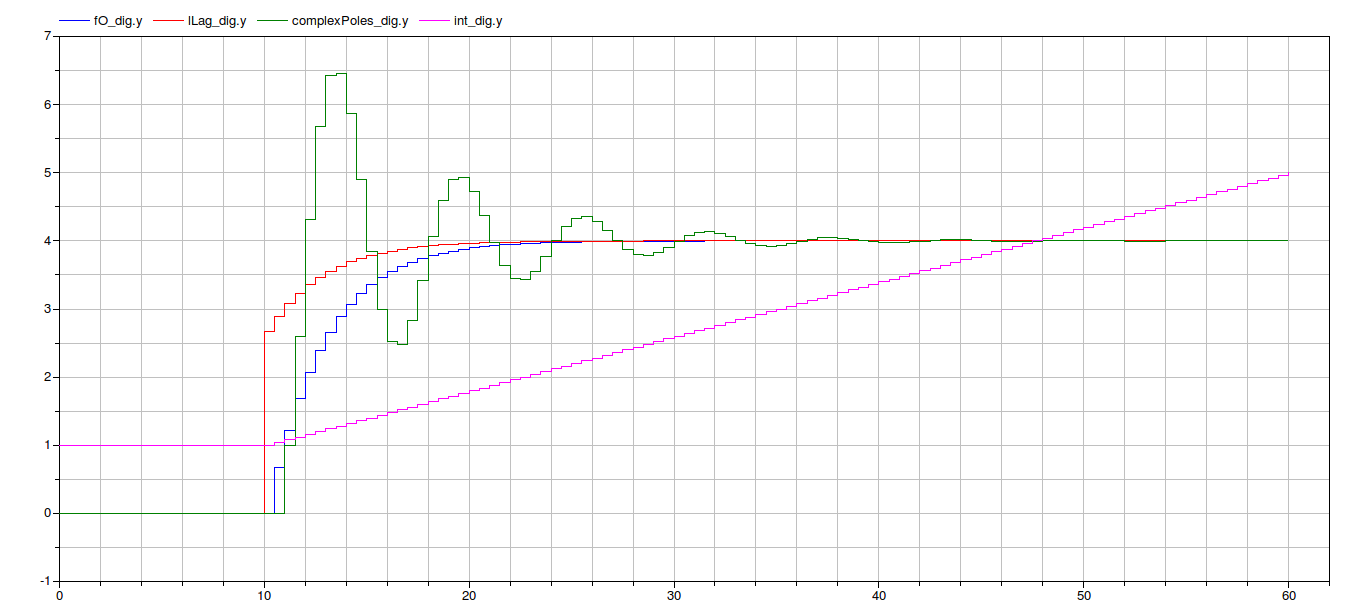
In this example are shown the step responces of various basic linear systems:
- integrator,
- first order,
- lead lag,
- and complex poles
For each continuous time system there is its discretised version. It is possible to modify the discretisation methods
as well the sampling time in order to see the changes.
Continuous time
Discrete time (Forward Euler)
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Integrator | |||
| Real | mu_int | 0.04 | Integrating process gain |
| Real | y_start_int | 1 | Integrating process initial condition |
| First Order | |||
| Real | mu_FO | 2 | First order process gain |
| Real | tau_FO | 3 | First order time constant |
| Real | y_start_FO | 0 | initial condition |
| Lead Lag | |||
| Real | mu_LL | 2 | Lead Lag process gain |
| Real | y_start_LL | 0 | Lead Lag initial condition |
| Real | T1_LL | 2 | Lead Lag time constant of the zero |
| Real | T2_LL | 3 | Lead Lag time constant of the pole |
| Complex poles | |||
| Real | mu_cpx | 2 | Complex poles process gain |
| Real | omegan_cpx | 1 | Complex poles natural frequency |
| Real | xi_cpx | 0.4 | Complex poles dumping factor |
| Real | y_start_cpx | 0 | Complex poles initial value |
| Real | dy_start_cpx | 0 | Complex poles initial slope |
| Discretisation | |||
| Real | Ts | 0.5 | Sampling time |
| IndustrialControlSystems.LinearSystems.Discrete.Types.discrMethod | method | IndustrialControlSystems.LinearSystems.Discrete.Types.discrMethod.FE | Method |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Continuous.Integrator | int | ||
| Discrete.Integrator | int_dig | ||
| Continuous.FirstOrder | fO | ||
| Discrete.FirstOrder | fO_dig | ||
| Continuous.LeadLag | lLag | ||
| Discrete.LeadLag | lLag_dig | ||
| Modelica.Blocks.Sources.Step | stepSignal | ||
| Continuous.ComplexPoles | complexPoles | ||
| Discrete.ComplexPoles | complexPoles_dig |
Revisions
- Industrial Control Systems (v 1.0.0) : April-May 2012
- List of revisions:
- 11 May 2012 (author: Marco Bonvini)
- Main Authors:
- Marco Bonvini; <bonvini@elet.polimi.it>
- Alberto Leva <leva@elet.polimi.it>
- Politecnico di Milano
- Dipartimento di Elettronica e Informazione
- Via Ponzio 34/5
- 20133 Milano - ITALIA -
- Copyright:
- Copyright © 2010-2012, Marco Bonvini and Alberto Leva.
- The IndustrialControlSystems package is free software; it can be redistributed and/or modified under the terms of the Modelica license.