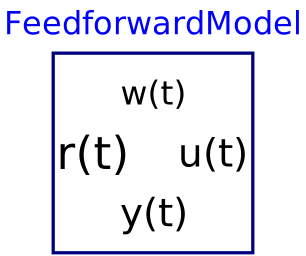
blockFeedforwardModel
Manual controller model from Drop et al. (2013) with compensatory and feedforward pathways
Extends from ManualTracking.Blocks.SI3SO (3 Single Input / 1 Single Output continuous control block with manual controller signal names), ManualTracking.Icons.ManualController.
Information

Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Real | K1 | 1 | Gain of compensatory path |
| Real | K2 | 1 | Gain of feedforward path |
| Real | tau1 | 0.25 | Time delay of compensatory path (s) |
| Real | tau2 | 0.25 | Time delay of feedforward path (s) |
| Real | T | 5 | Time constant of first-order lag in feedforward path (s) |
| Real | omega | 12 | Natural frequency of neuromuscular filter (rad/s) |
| Real | zeta | 0.2 | Damping ratio of neuromuscular filter |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Interfaces.RealInput | r (from SI3SO) | Reference state | |
| Modelica.Blocks.Interfaces.RealInput | y (from SI3SO) | Measured state | |
| Modelica.Blocks.Interfaces.RealInput | w (from SI3SO) | Disturbance input | |
| Modelica.Blocks.Interfaces.RealOutput | u (from SI3SO) | Control input |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Real | e (from SI3SO) | Difference between reference and measured states | |
| Real | v (from SI3SO) | Control input before disturbance input is added | |
| Modelica.Blocks.Math.Gain | gain | ||
| Modelica.Blocks.Continuous.FirstOrder | firstorder | ||
| Modelica.Blocks.Nonlinear.FixedDelay | timedelay1 | ||
| Modelica.Blocks.Nonlinear.FixedDelay | timedelay2 | ||
| ManualTracking.Blocks.FeedForward | feedforward | ||
| Modelica.Blocks.Continuous.SecondOrder | secondorderfilter | ||
| Modelica.Blocks.Math.Add | add2 |