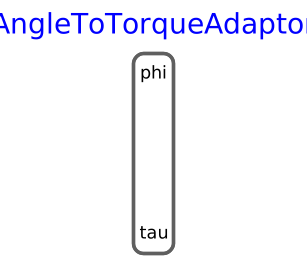
modelAngleToTorqueAdaptor
Signal adaptor for a Rotational flange with torque as output and angle, speed, and optionally acceleration as inputs (especially useful for FMUs)
Information
Adaptor between a flange connector and a signal representation of the flange.
This component is used to provide a pure signal interface around a Rotational model
and export this model in form of an input/output block,
especially as FMU (Functional Mock-up Unit).
Examples of the usage of this adaptor are provided in
Rotational.Examples.GenerationOfFMUs.
This adaptor has angle, angular velocity and angular acceleration as input signals and
torque as output signal. Note, the input signals must be consistent to each other
(w=der(phi), a=der(w)).
Parameters
| Type | Name | Default | Description |
|---|
| Boolean | use_w | true | = true, enable the input connector w (angular velocity) |
| Boolean | use_a | true | = true, enable the input connector a (angular acceleration) |
Contents
| Name | Description |
|---|
 Move_phiprotected | Forced movement of a flange according to an angle signal |
 Move_wprotected | Forced movement of a flange according to an angle and speed signal |
