
modelCurrentControlledDCPM
Current controlled DC PM drive with H-bridge from battery
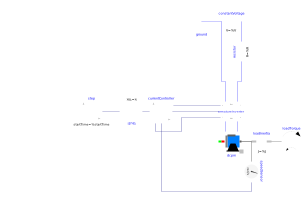
Extends from Utilities.PartialControlledDCPM (Partial controlled DC PM drive with H-bridge from battery).
Information
This model demonstrates how a current controller for a DC PM drive works.
The current controller is parameterized according to the absolute optimum.
At time=0.2 s a reference torque step is applied, causing the drive to accelerate until motor torque and load torque are at an equilibrium.
Further reading: Tutorial at the Modelica Conference 2017
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| DriveDataDCPM | driveData (from PartialControlledDCPM) |