
modelDCPM_CurrentControlled
Test example: DC with permanent magnet starting with current controller
Extends from Modelica.Icons.Example (Icon for runnable examples).
Information
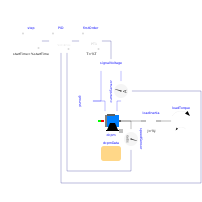
Test example: Permanent magnet DC machine started with current controllerThe current controller is parameterized according to absolute optimum. At time 0.1 s a reference current step with height = nominal armature current is applied, causing the DC machine to start, and accelerating inertias.
The machine is loaded by a quadratic speed dependent load torque.
Simulate for 2 seconds and plot (versus time):
- dcpm.ia: armature current
- dcpm.wMechanical: motor's speed
- dcpm.tauElectrical: motor's torque
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Torque | TLoad | ViNominal*dcpmData.IaNominal/dcpmData.wNominal | Nominal load torque |
| SI.AngularVelocity | wLoad | dcpmData.wNominal | Nominal load torque |
| SI.Inertia | JLoad | dcpmData.Jr | Load's moment of inertia |
| SI.Resistance | Ra | Modelica.Electrical.Machines.Thermal.convertResistance(dcpmData.Ra, dcpmData.TaRef, dcpmData.alpha20a, dcpmData.TaNominal) | Warm armature resistance |
| SI.Voltage | ViNominal | dcpmData.VaNominal - Ra*dcpmData.IaNominal | Nominal induced voltage |
| SI.Time | Ta | dcpmData.La/Ra | Armature time constant |
| SI.Time | Ts | 1e-3 | Dead time of inverter |
| SI.Resistance | k | Ra*Ta/(2*Ts) | Current controller proportional gain |
| SI.Time | Ti | Ta | Current controller integral time constant |
| SI.MagneticFlux | kPhi | ViNominal/dcpmData.wNominal | Voltage constant |
| Utilities.ParameterRecords.DcPermanentMagnetData | dcpmData | DC machine data |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Machines.BasicMachines.DCMachines.DC_PermanentMagnet | dcpm | ||
| Blocks.Sources.Step | step | ||
| Modelica.Electrical.Analog.Sources.SignalVoltage | signalVoltage | ||
| Modelica.Electrical.Analog.Basic.Ground | ground | ||
| Modelica.Mechanics.Rotational.Components.Inertia | loadInertia | ||
| Mechanics.Rotational.Sources.QuadraticSpeedDependentTorque | loadTorque | ||
| Analog.Sensors.CurrentSensor | currentSensor | ||
| Mechanics.Rotational.Sensors.SpeedSensor | speedSensor | ||
| Blocks.Continuous.FirstOrder | firstOrder | ||
| Blocks.Continuous.LimPID | PID |