
modelIMC_Inverter
Induction machine with squirrel cage and inverter
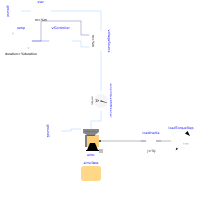
Extends from Modelica.Icons.Example (Icon for runnable examples).
Information
An ideal frequency inverter is modeled by using a VfController and a three-phase SignalVoltage.
Frequency is raised by a ramp, causing the induction machine with squirrel cage to start,
and accelerate inertias. At time tStep a load step is applied.
Simulate for 1.5 seconds and plot (versus time):
currentQuasiRMSSensor.I: stator current RMSaimc.wMechanical: machine speedaimc.tauElectrical: machine torquefs: stator frequencyfr: rotor frequencys: slip
Compare with transient models IMC_Inverter (Electrical.Machines) and IMC_Inverter (FundamentalWave). Note that electrical transients are neglected, but mechanical transients are taken into account.
Theoretical thoughts
By setting the stator resistance Rs = 0, comparing quasistatic points of operation for different stator frequencies fs,
it can be seen that
- in the base region
fs ≤ fNominalrotor frequencyfris constant, if the load torque is constant, - whereas in the field weakening region
f ≥ fNominalslip is constant, if load torque is adapted according totau = tauNominal*fNominal/f.
Default machine parameters are used.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Integer | m | 3 | Number of phases |
| SI.Voltage | VNominal | 100 | Nominal RMS voltage per phase |
| SI.Frequency | fNominal | 50 | Nominal frequency |
| SI.Frequency | f | 50 | Maximum operational frequency |
| SI.Time | tRamp | 1 | Frequency ramp |
| SI.Torque | TLoad | 161.4*min(1, fNominal/abs(f)) | Nominal load torque |
| SI.Time | tStep | 1.2 | Time of load torque step |
| SI.Inertia | JLoad | 0.29 | Load's moment of inertia |
| Modelica.Electrical.Machines.Utilities.ParameterRecords.IM_SquirrelCageData | aimcData | Induction machine data |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Frequency | fs | ramp.y | Stator frequency |
| SI.Frequency | fr | s*fs | Rotor frequency |
| Real | s | if noEvent(abs(fs) < small) then 0 else 1 - aimc.wMechanical*aimcData.p/(2*pi*fs) | Slip |
| Modelica.Magnetic.QuasiStatic.FundamentalWave.BasicMachines.InductionMachines.IM_SquirrelCage | aimc | ||
| Modelica.Electrical.QuasiStatic.Polyphase.Sensors.CurrentQuasiRMSSensor | currentQuasiRMSSensor | ||
| Modelica.Blocks.Sources.Ramp | ramp | ||
| Modelica.Magnetic.QuasiStatic.FundamentalWave.Utilities.VfController | vfController | ||
| Modelica.Electrical.QuasiStatic.Polyphase.Sources.VariableVoltageSource | voltageSource | ||
| Modelica.Electrical.QuasiStatic.Polyphase.Basic.Star | star | ||
| Modelica.Electrical.QuasiStatic.SinglePhase.Basic.Ground | ground | ||
| Modelica.Mechanics.Rotational.Components.Inertia | loadInertia | ||
| Modelica.Mechanics.Rotational.Sources.TorqueStep | loadTorqueStep | ||
| Modelica.Magnetic.QuasiStatic.FundamentalWave.Utilities.TerminalBox | terminalBox | ||
| Modelica.Electrical.QuasiStatic.SinglePhase.Basic.Ground | ground1 |