modelSystemWithStandardBodies
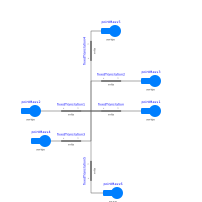
For comparison purposes, an equivalent model with Bodies instead of PointMasses
Information
In order to compare the results of the "PointMass" example where 6 point masses are rigidly connected together, in this comparison model, an equivalent system is setup, with the only difference that the point masses are replaced by Bodies with zero inertia.
Components
| Type | Name | Default | Description |
|---|---|---|---|
| PointMass | pointMass1 | ||
| PointMass | pointMass2 | ||
| PointMass | pointMass3 | ||
| PointMass | pointMass4 | ||
| PointMass | pointMass5 | ||
| PointMass | pointMass6 | ||
| Modelica.Mechanics.MultiBody.Parts.FixedTranslation | fixedTranslation | ||
| Modelica.Mechanics.MultiBody.Parts.FixedTranslation | fixedTranslation1 | ||
| Modelica.Mechanics.MultiBody.Parts.FixedTranslation | fixedTranslation2 | ||
| Modelica.Mechanics.MultiBody.Parts.FixedTranslation | fixedTranslation3 | ||
| Modelica.Mechanics.MultiBody.Parts.FixedTranslation | fixedTranslation4 | ||
| Modelica.Mechanics.MultiBody.Parts.FixedTranslation | fixedTranslation5 |
Contents
| Name | Description |
|---|---|
 PointMass | Body used at all places of the comparison model with zero inertia tensor |