packageElementary
Elementary examples to demonstrate various features of the MultiBody library
Extends from Modelica.Icons.ExamplesPackage (Icon for packages containing runnable examples).
Information
This package contains elementary example models to demonstrate the usage of the MultiBody library
Content
| Model | Description |
|---|---|
| DoublePendulum DoublePendulumInitTip |
Simple double pendulum with two revolute joints and two bodies. In DoublePendulumInitTip, the initial position of the pendulum tip is given
instead of common initialization by pendulum angles.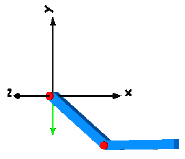
|
| ForceAndTorque | Demonstrates usage of Forces.ForceAndTorque element.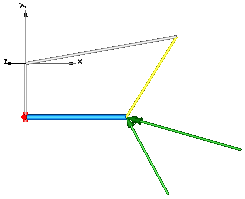
|
| FreeBody | Free flying body attached by two springs to environment.
|
| InitSpringConstant | Determine spring constant such that system is in steady state
at given position.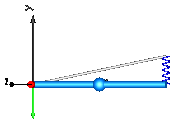
|
| LineForceWithTwoMasses | Demonstrates a line force with two point masses using a
Joints.Assemblies.JointUPS and alternatively a
Forces.LineForceWithTwoMasses component.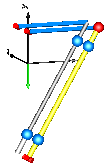
|
| Pendulum | Simple pendulum with one revolute joint and one body.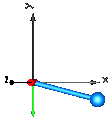
|
| PendulumWithSpringDamper | Simple spring/damper/mass system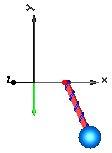
|
| PointGravity | Two bodies in a point gravity field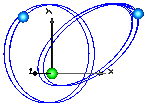
|
| PointGravityWithPointMasses | Two point masses in a point gravity field (rotation of bodies is neglected)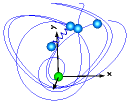
|
| PointGravityWithPointMasses2 | Rigidly connected point masses in a point gravity field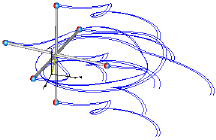
|
| RollingWheel | Single wheel rolling on ground starting from an initial speed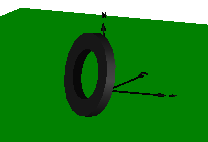
|
| RollingWheelSetDriving | Rolling wheel set that is driven by torques driving the wheels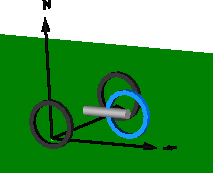
|
| RollingWheelSetPulling | Rolling wheel set that is pulled by a force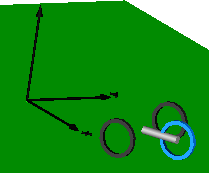
|
| SpringDamperSystem | Spring/damper system with a prismatic joint and
attached on free flying body
|
| SpringMassSystem | Mass attached via a prismatic joint and a spring to the world frame
|
| SpringWithMass | Point mass hanging on a spring
|
| ThreeSprings | 3-dimensional springs in series and parallel connection
|
| HeatLosses | Demonstrate the modeling of heat losses. |
| UserDefinedGravityField | Demonstrate the modeling of a user-defined gravity field. |
| Surfaces | Demonstrate the visualization of a sine surface,
as well as a torus and a wheel constructed from a surface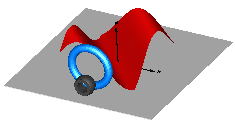
|
Contents
| Name | Description |
|---|---|
 DoublePendulum | Simple double pendulum with two revolute joints and two bodies |
| DoublePendulumInitTip | Demonstrate how to initialize a double pendulum so that its tip starts at a predefined position |
| ForceAndTorque | Demonstrate usage of ForceAndTorque element |
| FreeBody | Free flying body attached by two springs to environment |
| InitSpringConstant | Determine spring constant such that system is in steady state at given position |
| LineForceWithTwoMasses | Demonstrate line force with two point masses using a JointUPS and alternatively a LineForceWithTwoMasses component |
| Pendulum | Simple pendulum with one revolute joint and one body |
| PendulumWithSpringDamper | Simple spring/damper/mass system |
| PointGravity | Two point masses in a point gravity field |
| PointGravityWithPointMasses | Two point masses in a point gravity field (rotation of bodies is neglected) |
| PointGravityWithPointMasses2 | Rigidly connected point masses in a point gravity field |
| SpringDamperSystem | Simple spring/damper/mass system |
| SpringMassSystem | Mass attached with a spring to the world frame |
| SpringWithMass | Point mass hanging on a spring |
| ThreeSprings | 3-dim. springs in series and parallel connection |
| RollingWheel | Single wheel rolling on ground starting from an initial speed |
| RollingWheelSetDriving | Rolling wheel set that is driven by torques driving the wheels |
| RollingWheelSetPulling | Rolling wheel set that is pulled by a force |
| HeatLosses | Demonstrate the modeling of heat losses |
| UserDefinedGravityField | Demonstrate the modeling of a user-defined gravity field |
| Surfaces | Demonstrate the visualization of a sine surface, as well as a torus and a wheel constructed from a surface |
 Utilities | Utility classes for elementary multi-body example models |