
modelEngineV6_analytic
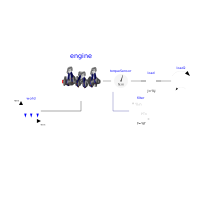
Extends from Modelica.Icons.Example (Icon for runnable examples).
Information
This is a similar model as the example "EngineV6". However, the cylinders have been built up with component Modelica.Mechanics.MultiBody.Joints.Assemblies.JointRRR that solves the non-linear system of equations in an aggregation of 3 revolution joints analytically and only one body is used that holds the total mass of the crank shaft:
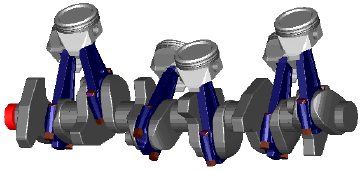
This model is about 20 times faster as the EngineV6 example and no linear or non-linear system of equations occur. In contrast, the "EngineV6" example leads to 6 systems of nonlinear equations (every system has dimension = 5, with Evaluate=false and dimension=1 with Evaluate=true) and a linear system of equations of about 40. This shows the power of the analytic loop handling.
Simulate for 3 s with about 50000 output intervals, and plot the variables engineSpeed_rpm, engineTorque, and filteredEngineTorque. Note, the result file has a size of about 240 Mbyte in this case. The default setting of StopTime = 1.01 s (with the default setting of the tool for the number of output points), in order that (automatic) regression testing does not have to cope with a large result file.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | animation | true | = true, if animation shall be enabled |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Units.NonSI.AngularVelocity_rpm | engineSpeed_rpm | Modelica.Units.Conversions.to_rpm(load.w) | Engine speed |
| SI.Torque | engineTorque | filter.u | Torque generated by engine |
| SI.Torque | filteredEngineTorque | filter.y | Filtered torque generated by engine |
| Modelica.Mechanics.MultiBody.World | world | ||
| Utilities.EngineV6_analytic | engine | ||
| Modelica.Mechanics.Rotational.Components.Inertia | load | ||
| Modelica.Mechanics.Rotational.Sources.QuadraticSpeedDependentTorque | load2 | ||
| Rotational.Sensors.TorqueSensor | torqueSensor | ||
| Blocks.Continuous.CriticalDamping | filter |