modelRollingWheel
Information
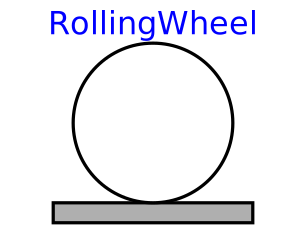
A joint for a wheel rolling on the x-y plane of the world frame. The rolling contact is considered being ideal, i.e. there is no slip between the wheel and the ground. This is simply gained by two non-holonomic constraint equations on velocity level defined for both longitudinal and lateral direction of the wheel. There is also a holonomic constraint equation on position level granting a permanent contact of the wheel to the ground, i.e. the wheel can not take off.
The origin of the frame frame_a is placed in the intersection of the wheel spin axis with the wheel middle plane and rotates with the wheel itself. The y-axis of frame_a is identical with the wheel spin axis, i.e. the wheel rotates about y-axis of frame_a. A wheel body collecting the mass and inertia should be connected to this frame.
Note
To work properly, the gravity acceleration vector g of the world must point in the negative z-axis, i.e.
inner Modelica.Mechanics.MultiBody.World world(n={0,0,-1});
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Radius | radius | Wheel radius | |
| StateSelect | stateSelect | StateSelect.always | Priority to use generalized coordinates as states |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.MultiBody.Interfaces.Frame_a | frame_a | Frame fixed in wheel center point. x-Axis: upwards, y-axis: along wheel axis |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Position | x | x-coordinate of wheel axis | |
| SI.Position | y | y-coordinate of wheel axis | |
| SI.Position | z | ||
| SI.Angle[3] | angles | Angles to rotate world-frame into frame_a around z-, y-, x-axis | |
| SI.AngularVelocity[3] | der_angles | Derivative of angles | |
| SI.Position[3] | r_road_0 | Position vector from world frame to contact point on road, resolved in world frame | |
| SI.Force[3] | f_wheel_0 | Contact force acting on wheel, resolved in world frame | |
| SI.Force | f_n | Contact force acting on wheel in normal direction | |
| SI.Force | f_lat | Contact force acting on wheel in lateral direction | |
| SI.Force | f_long | Contact force acting on wheel in longitudinal direction | |
| SI.Position | err | |r_road_0 - frame_a.r_0| - radius (must be zero; used for checking) |