modelPointMass
Information
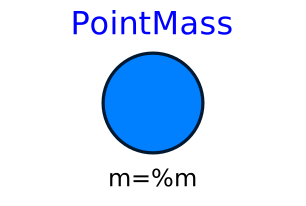
Rigid body where the inertia tensor is neglected. This body is solely defined by its mass. By default, this component is visualized by a sphere that has its center at frame_a. Note, that the animation may be switched off via parameter animation = false.
Every PointMass has potential states. If possible a tool will select the states of joints and not the states of PointMass because this is usually the most efficient choice. In this case the position and velocity of frame_a of the body will be computed by the component that is connected to frame_a. However, if a PointMass is moving freely in space, variables of the PointMass have to be used as states. The potential states are: The position vector frame_a.r_0 from the origin of the world frame to the origin of frame_a of the body, resolved in the world frame and the absolute velocity v_0 of the origin of frame_a, resolved in the world frame (= der(frame_a.r_0)).
Whether or not variables of the body are used as states is usually automatically selected by the Modelica translator. If parameter enforceStates is set to true in the "Advanced" menu, then PointMass variables frame_a.r_0 and der(frame_a.r_0) are forced to be used as states.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | animation | true | = true, if animation shall be enabled (show sphere) |
| SI.Mass | m | Mass of mass point | |
| Advanced | |||
| StateSelect | stateSelect | StateSelect.avoid | Priority to use frame_a.r_0, v_0 (= der(frame_a.r_0)) as states |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Interfaces.Frame_a | frame_a | Coordinate system fixed at center of mass point |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Diameter | sphereDiameter | world.defaultBodyDiameter | Diameter of sphere |
| Types.Color | sphereColor | Modelica.Mechanics.MultiBody.Types.Defaults.BodyColor | Color of sphere |
| Types.SpecularCoefficient | specularCoefficient | world.defaultSpecularCoefficient | Reflection of ambient light (= 0: light is completely absorbed) |
| SI.Position[3] | r_0 | Position vector from origin of world frame to origin of frame_a, resolved in world frame | |
| SI.Velocity[3] | v_0 | Absolute velocity of frame_a, resolved in world frame (= der(r_0)) | |
| SI.Acceleration[3] | a_0 | Absolute acceleration of frame_a resolved in world frame (= der(v_0)) |