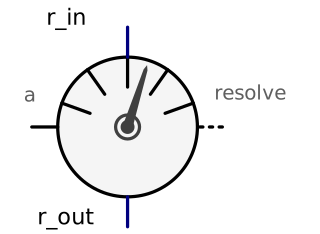
modelTransformAbsoluteVector
Transform absolute vector in to another frame
Extends from Modelica.Icons.RoundSensor (Icon representing a round measurement device).
Information
The input vector "Real r_in[3]" is assumed to be an absolute kinematic quantity of frame_a that is defined to be resolved in the frame defined with parameter "frame_r_in". This model resolves vector r_in in the coordinate system defined with parameter "frame_r_out" and returns the transformed output vector as "Real r_out[3]";
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.MultiBody.Types.ResolveInFrameA | frame_r_in | Modelica.Mechanics.MultiBody.Types.ResolveInFrameA.frame_a | Frame in which vector r_in is resolved (world, frame_a, or frame_resolve) |
| Modelica.Mechanics.MultiBody.Types.ResolveInFrameA | frame_r_out | frame_r_in | Frame in which vector r_in shall be resolved and provided as r_out (world, frame_a, or frame_resolve) |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.MultiBody.Interfaces.Frame_a | frame_a | Coordinate system from which absolute kinematic quantities are measured | |
| Modelica.Mechanics.MultiBody.Interfaces.Frame_resolve | frame_resolve | Coordinate system in which r_in or r_out is optionally resolved | |
| Blocks.Interfaces.RealInput[3] | r_in | Input vector resolved in frame defined by frame_r_in | |
| Blocks.Interfaces.RealOutput[3] | r_out | Input vector r_in resolved in frame defined by frame_r_out |