
modelFirstGrounded
First example: simple drive train with grounded elements
Extends from Modelica.Icons.Example (Icon for runnable examples).
Information
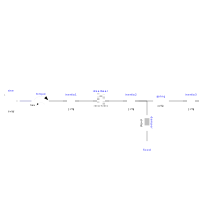
The drive train consists of a motor inertia which is driven by a sine-wave motor torque. Via a gearbox the rotational energy is transmitted to a load inertia. Elasticity in the gearbox is modeled by a spring element. A linear damper is used to model the damping in the gearbox bearing.
Note, that a force component (like the damper of this example) which is acting between a shaft and the housing has to be fixed in the housing on one side via component Fixed.
Simulate for 1 second and plot the following variables:
angular velocities of inertias inertia2 and 3: inertia2.w, inertia3.w
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Torque | amplitude | 10 | Amplitude of driving torque |
| SI.Frequency | f | 5 | Frequency of driving torque |
| SI.Inertia | Jmotor | 0.1 | Motor inertia |
| SI.Inertia | Jload | 2 | Load inertia |
| Real | ratio | 10 | Gear ratio |
| Real | damping | 10 | Damping in bearing of gear |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Rotational.Components.Fixed | fixed | ||
| Rotational.Sources.Torque | torque | ||
| Rotational.Components.Inertia | inertia1 | ||
| Rotational.Components.IdealGear | idealGear | ||
| Rotational.Components.Inertia | inertia2 | ||
| Rotational.Components.Spring | spring | ||
| Rotational.Components.Inertia | inertia3 | ||
| Rotational.Components.Damper | damper | ||
| Modelica.Blocks.Sources.Sine | sine |