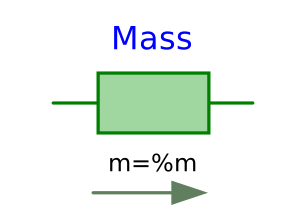
modelMass
Sliding mass with inertia
Extends from Translational.Interfaces.PartialRigid (Rigid connection of two translational 1D flanges).
Information
Sliding mass with inertia, without friction and two rigidly connected flanges.
The sliding mass has the length L, the position coordinate s is in the middle. Sign convention: A positive force at flange flange_a moves the sliding mass in the positive direction. A negative force at flange flange_a moves the sliding mass to the negative direction.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Mass | m | Mass of the sliding mass | |
| SI.Length | L (from PartialRigid) | Length of component, from left flange to right flange (= flange_b.s - flange_a.s) | |
| Advanced | |||
| StateSelect | stateSelect | StateSelect.default | Priority to use s and v as states |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Flange_a | flange_a (from PartialTwoFlanges) | (left) driving flange (flange axis directed into cut plane, e. g. from left to right) | |
| Flange_b | flange_b (from PartialTwoFlanges) | (right) driven flange (flange axis directed out of cut plane) |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Position | s (from PartialRigid) | Absolute position of center of component (s = flange_a.s + L/2 = flange_b.s - L/2) | |
| SI.Velocity | v | Absolute velocity of component | |
| SI.Acceleration | a | Absolute acceleration of component |