
modelSensors
Sensors for translational systems
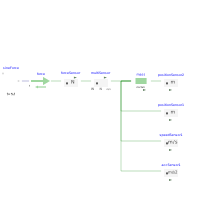
Extends from Modelica.Icons.Example (Icon for runnable examples).
Information
These sensors measure
force f in N
position s in m
velocity v in m/s
acceleration a in m/s2
In this example, the measured velocity and acceleration is independent of
the flange the sensor is connected to. In contrast, the measured position
depends on the flange (flange_a or flange_b) and the
length L of the component.
Plot positionSensor1.s, positionSensor2.s and mass.s
to see the difference.
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Translational.Sensors.ForceSensor | forceSensor | ||
| Modelica.Mechanics.Translational.Sensors.MultiSensor | multiSensor | ||
| Translational.Sensors.SpeedSensor | speedSensor1 | ||
| Translational.Sensors.PositionSensor | positionSensor1 | ||
| Translational.Sensors.AccSensor | accSensor1 | ||
| Translational.Sensors.PositionSensor | positionSensor2 | ||
| Translational.Components.Mass | mass | ||
| Translational.Sources.Force | force | ||
| Modelica.Blocks.Sources.Sine | sineForce |