modelInverseInertia
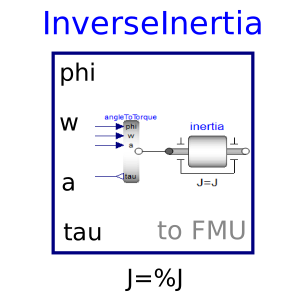
Input/output block of an inverse inertia model
Extends from Modelica.Blocks.Icons.Block (Basic graphical layout of input/output block).
Information
A rotational component with pure signal interface which can be applied for
a FMU (Functional Mock-up Unit)
exchange.
Based on the kinematic inputs applied on a component with inertia
the output torque tau is returned.
See also
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Inertia | J | 1 | Inertia |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Interfaces.RealInput | phi | Angle to drive the inertia | |
| Modelica.Blocks.Interfaces.RealInput | w | Speed to drive the inertia | |
| Modelica.Blocks.Interfaces.RealInput | a | Acceleration to drive the inertia | |
| Modelica.Blocks.Interfaces.RealOutput | tau | Torque needed to drive the flange according to phi, w, a |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.Rotational.Components.Inertia | inertia | ||
| Modelica.Mechanics.Rotational.Components.GeneralAngleToTorqueAdaptor | angleToTorque |