blockFirstOrder
First order (continuous or discrete) transfer function block (= 1 pole)
Extends from Interfaces.PartialSISO2 (Partial Single Input Single Output (continuous or discrete) control block of Controller library).
Information
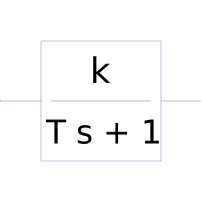
This blocks defines the transfer function between the input u and the output y as first order system:
             k
     y = --------- * u
         T * s + 1
The block can be continuous or discrete (with continuous parameterization).
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | continuous (from PartialSampledBlock) | blockType == Types.BlockTypeWithGlobalDefault.Continuous or blockType == Types.BlockTypeWithGlobalDefault.UseSampleClockOption and sampleClock.blockType == Types.BlockType.Continuous | True, if continuous block, otherwise discrete block |
| Types.Init | init (from PartialSampledBlock) | Modelica_LinearSystems2.Controllers.Internal.convertToInit(initType, sampleClock.initType) | Type of initialization (no init/steady state/initial state/initial output) |
| Real | k | 1 | Gain |
| Real | T | 1 | Time Constant |
| Advanced options | |||
| Types.BlockTypeWithGlobalDefault | blockType (from PartialSampledBlock) | Modelica_LinearSystems2.Controllers.Types.BlockTypeWithGlobalDefault.UseSampleClockOption | Type of block |
| Types.InitWithGlobalDefault | initType (from PartialSampledBlock) | Types.InitWithGlobalDefault.UseSampleClockOption | Type of initialization (no init/steady state/initial state/initial output) |
| Real | y_start | 0.0 | Initial y if initType=InitialState (else guess) |
| Advanced options › Discrete block parameters | |||
| Types.MethodWithGlobalDefault | methodType (from PartialSampledBlock) | Types.MethodWithGlobalDefault.UseSampleClockOption | Type of discretization if discrete block |
| Integer | sampleFactor (from PartialSampledBlock) | 1 | Sample factor (Ts = sampleFactor * sampleClock.sampleTime) |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Interfaces.RealInput | u (from PartialSISO2) | Continuous or discrete input signal of block | |
| Modelica.Blocks.Interfaces.RealOutput | y (from PartialSISO2) | Continuous or discrete output signal of block |