blockStateSpace
Continuous or discrete state space system block
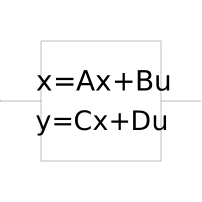
Extends from Interfaces.PartialSampledBlock (Partial block of Sampled library (icon + default parameters)).
Information
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica_LinearSystems2.StateSpace | system | Modelica_LinearSystems2.StateSpace(A = fill(0, 0, 0), B = fill(0, 0, 1), C = fill(0, 1, 0), D = fill(0, 1, 1)) | Continuous linear time-invariant system |
| Boolean | continuous (from PartialSampledBlock) | blockType == Types.BlockTypeWithGlobalDefault.Continuous or blockType == Types.BlockTypeWithGlobalDefault.UseSampleClockOption and sampleClock.blockType == Types.BlockType.Continuous | True, if continuous block, otherwise discrete block |
| Types.Init | init (from PartialSampledBlock) | Modelica_LinearSystems2.Controllers.Internal.convertToInit(initType, sampleClock.initType) | Type of initialization (no init/steady state/initial state/initial output) |
| Integer | nx | size(system.A, 1) | Number of states x |
| Integer | ny | size(system.C, 1) | Number of outputs y |
| Advanced options | |||
| Types.BlockTypeWithGlobalDefault | blockType (from PartialSampledBlock) | Modelica_LinearSystems2.Controllers.Types.BlockTypeWithGlobalDefault.UseSampleClockOption | Type of block |
| Types.InitWithGlobalDefault | initType (from PartialSampledBlock) | Types.InitWithGlobalDefault.UseSampleClockOption | Type of initialization (no init/steady state/initial state/initial output) |
| Real[nx] | x_start | zeros(nx) | Initial or guess values of states |
| Real[ny] | y_start | zeros(ny) | Initial values of outputs (remaining states are in steady state if possible) |
| Boolean | withDelay | false | True, if a unit delay should be considered |
| Advanced options › Discrete block parameters | |||
| Types.MethodWithGlobalDefault | methodType (from PartialSampledBlock) | Types.MethodWithGlobalDefault.UseSampleClockOption | Type of discretization if discrete block |
| Integer | sampleFactor (from PartialSampledBlock) | 1 | Sample factor (Ts = sampleFactor * sampleClock.sampleTime) |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Interfaces.RealInput[size(system.B, 2)] | u | Continuous or discrete input signals of block | |
| Modelica.Blocks.Interfaces.RealOutput[size(system.C, 1)] | y | Continuous or discrete output signals of block | |
| Modelica.Blocks.Interfaces.RealOutput[nx] | x | State vector of continuous system |