modelControlledSISO2
Controlled SISO system with parameters different to ControlledSISO1
Extends from ControlledSISO1 (Controlled SISO system).
Information
Utility model in order to demonstrate the plotting of a root locus:
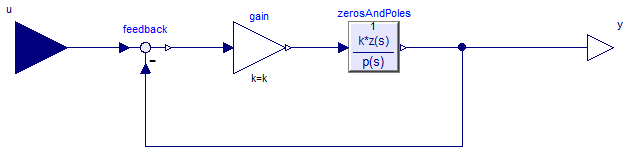
This model consists of a linear, time invariant single-input, single-output plant "zerosAndPoles"
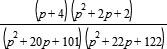
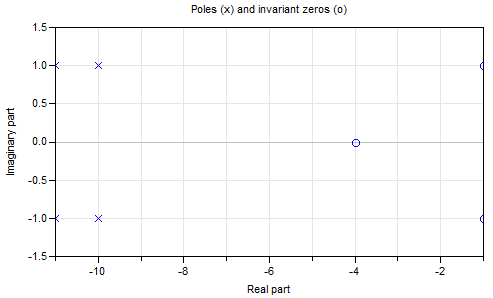
that is controlled by a P-Controller with a constant gain k. The pole/zero pattern of the plant is shown in the next figure:
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Real | k (from ControlledSISO1) | 1 |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| RealInput | u (from SISO) | Connector of Real input signal | |
| RealOutput | y (from SISO) | Connector of Real output signal |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Controllers.ZerosAndPoles | zerosAndPoles (from ControlledSISO1) | ||
| Modelica.Blocks.Math.Feedback | feedback (from ControlledSISO1) | ||
| Modelica.Blocks.Math.Gain | gain (from ControlledSISO1) | ||
| Controllers.SampleClock | sampleClock (from ControlledSISO1) |