modelRobot
Robot that can be connected to a horizontal table
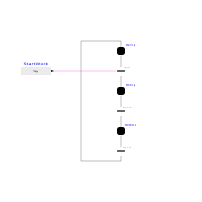
Extends from Task.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| String | processor (from Task) | "" | The processor that will execute the task |
| String | container (from Task) | "" | The task in which the controller will run |
| Integer | priority (from Task) | 1 | Priority of the task |
| Real | sampleTime (from Task) | 0.01 | Sample time of the task |
| Real | phase (from Task) | 0 | Phase of the task |
| Real | weldPoints | {{16, 24}, {30, 16}, {30.2285, 22.627}, {32, 74}, {32, 25.1191}, {32, 16}, {40, 22}, {32, 16}, {34.5977, 13.7734}, {46, 4}, {33.2656, 13.5508}, {30, 16}, {26, 2}, {30, 16}, {18, 12}, {30, 16}, {30, 16}, {16, 24}} |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica_StateGraph2.Examples.Applications.ProductionLine.Internal.Connectors.RobotComRobot | robotComRobot |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Sources.BooleanExpression | StartWork | ||
| Real | PolOnePoints | Coordinates of polygon number one | |
| Real | PolTwoPoints | Coordinates of polygon number two | |
| Real | PolThreePoints | Coordinates of polygon number three | |
| Modelica_StateGraph2.Step | Waiting | ||
| Modelica_StateGraph2.Transition | start_work | ||
| Modelica_StateGraph2.Step | Working | ||
| Modelica_StateGraph2.Transition | finished_work | ||
| Modelica_StateGraph2.Step | WorkDone | ||
| Modelica_StateGraph2.Transition | return_to_wait |