modelTable
Table Logic
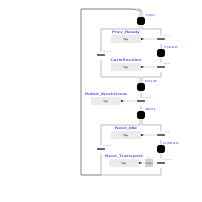
Extends from Task.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| String | processor (from Task) | "" | The processor that will execute the task |
| String | container (from Task) | "" | The task in which the controller will run |
| Integer | priority (from Task) | 1 | Priority of the task |
| Real | sampleTime (from Task) | 0.01 | Sample time of the task |
| Real | phase (from Task) | 0 | Phase of the task |
| Real | transportLength | 2*100 | Length of the table in pixels |
| Real | transportTime | 4 | Desired time to travel through table length |
| Real | carLength | 100 | Length of the car |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Real | pos | Current position of the car | |
| Real | newPoints | Coordinates for animation of the car | |
| Boolean | carInPosition | Signal that car is in position | |
| Modelica.Blocks.Sources.BooleanExpression | Prev_Ready | ||
| Modelica.Blocks.Sources.BooleanExpression | Next_Idle | ||
| Modelica.Blocks.Sources.BooleanExpression | Next_Transport | ||
| Modelica.Blocks.Sources.BooleanExpression | Robot_WorkDone | ||
| Modelica.Blocks.Sources.BooleanExpression | CarInPosition | ||
| Modelica.Blocks.Logical.Not | Not | ||
| Modelica_StateGraph2.Step | InTransport | ||
| Modelica_StateGraph2.Transition | limit_switch | ||
| Modelica_StateGraph2.Transition | prev_ready | ||
| Modelica_StateGraph2.Step | Empty | ||
| Modelica_StateGraph2.Transition | prev_receive | ||
| Modelica_StateGraph2.Step | Occupied | ||
| Modelica_StateGraph2.Transition | robot_work_done | ||
| Modelica_StateGraph2.Step | Waiting | ||
| Modelica_StateGraph2.Transition | next_idle | ||
| Modelica_StateGraph2.Transition | next_remove | ||
| Modelica_StateGraph2.Step | OutTransport | ||
| Modelica_StateGraph2.Transition | next_transport |