modelTurnTable
Table which turns the track
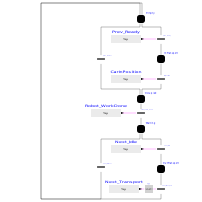
Extends from Task.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| String | processor (from Task) | "" | The processor that will execute the task |
| String | container (from Task) | "" | The task in which the controller will run |
| Integer | priority (from Task) | 1 | Priority of the task |
| Real | sampleTime (from Task) | 0.01 | Sample time of the task |
| Real | phase (from Task) | 0 | Phase of the task |
| Real | transportLength | 2*100 | Length of the track in pixels |
| Real | transportTime | 4 | Desired time to travel through table length |
| Real | carLength | 286 | Length of the car |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica_StateGraph2.Examples.Applications.ProductionLine.Internal.Connectors.TableComNext | tableComNext | ||
| Modelica_StateGraph2.Examples.Applications.ProductionLine.Internal.Connectors.TableComPrev | tableComPrev |