modelCoordinateSystem
Visualizing an orthogonal coordinate system of three axes
Information
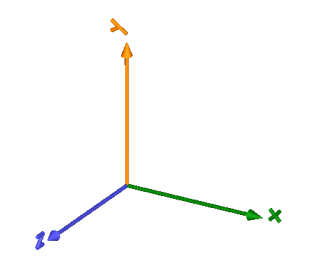
This element enables visualization of an orthogonal coordinate system as shown in the following picture.
The variables r, R and r_shape
are declared as (time varying) input variables.
If the default equation is not appropriate, a corresponding
modifier equation has to be provided in the
model where a CoordinateSystem instance is used, e.g., in the form
PlanarMechanics.Visualizers.Advanced.CoordinateSystem coordinateSystem(r = {sin(time), 0, 0.3});
Color of each axis can be set individually using a RGB color space given in the range 0 .. 255. Predefined colors from Types.Defaults are used throughout the library to get a coherent visualization.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Length | axisLength | planarWorld.nominalLength/2 | Length of world axes arrows |
| SI.Diameter | axisDiameter | axisLength/planarWorld.defaultFrameDiameterFraction | Diameter of world axes arrows |
| MB.Types.Color | color_x | PlanarMechanics.Types.Defaults.FrameColor | Color of x-arrow |
| MB.Types.Color | color_y | color_x | Color of y-arrow |
| MB.Types.Color | color_z | color_x | Color of z-arrow |
| Axes labels | |||
| Boolean | axisShowLabels | true | True, if labels shall be shown |
| SI.Length | labelStart | 1.05*axisLength | |
| SI.Length | scaledLabel | PlanarMechanics.Types.Defaults.FrameLabelHeightFraction*axisDiameter | |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Position[3] | r | {0, 0, 0} | Position vector from origin of world frame to origin of object frame, resolved in world frame |
| MB.Frames.Orientation | R | MB.Frames.nullRotation() | Orientation object to rotate the world frame into the object frame |
| SI.Position[3] | r_shape | {0, 0, 0} | Position vector from origin of object frame to shape origin, resolved in object frame |