modelDerivativeLag
Derivative filter with lag
Extends from Modelica.Blocks.Interfaces.SISO (Single Input Single Output continuous control block).
Information
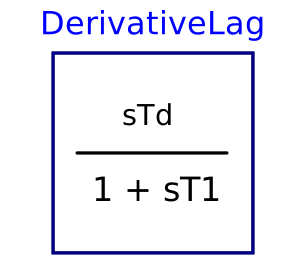
Implements a derivative filter with lag, a.k.a. real differentiator: y s*Td
- = -------------
u 1 + s*T1
If Td = T1 > 0, a high-pass or washout filter with cut-off frequency 1/Td is obtained.
If Td = T1 = 0 a filter with transfer function 1 is obtained.
By default, T1 and T2 are structural parameters, so they cannot be changed at runtime without recompiling the model. In order to do so, set the noDynamics parameter explicitly to false (note that you can't set T1 and T2 to zero = 0 at runtime in this case).
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Time | T1 | Lag time constant | |
| SI.Time | Td | T1 | Derivative time constant |
| Boolean | noDynamics | not (T1 > 0) | Trivial configuration with no dynamics G(s) = 1 |
| Initialization | |||
| Modelica.Blocks.Types.Init | initType | Modelica.Blocks.Types.Init.NoInit | Type of initialization (1: no init, 2: steady state, 3/4: initial output) |
| Real | yStart | 0 | Initial or guess value of output (= state) |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| RealInput | u (from SISO) | Connector of Real input signal | |
| RealOutput | y (from SISO) | Connector of Real output signal |
Components
| Type | Name | Default | Description |
|---|---|---|---|
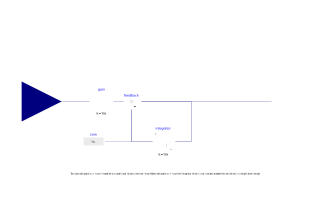
| Modelica.Blocks.Math.Feedback | feedback | ||
| Modelica.Blocks.Math.Gain | gain | ||
| Modelica.Blocks.Continuous.Integrator | integrator | ||
| Modelica.Blocks.Sources.RealExpression | zero |