modelAsynchron_ctrl
Asynchronous machine, cage-rotor, for field-oriented control, 3-phase dq0
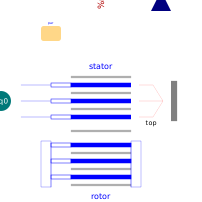
Extends from Partials.AsynchronBase (Asynchronous machine base, 3-phase dq0).
Information
This model is intended for field-oriented control. The input/output current-signals 'i_meas'/'i_act' represent the pu stator current in the rotorflux-fixed reference system:
  first component   ('field'): pu current in rotorflux d-axis
  second component ('torque'): pu current in rotorflux q-axis (q 90deg pos vs d)
The mapping from current demand to voltage demand is based on the steady-state equations of the machine.
Equivalent circuit is on diagram layer of parameter record ACdq0.Machines.Parameters.*
More information see Partials.AsynchronBase.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Integer | pp (from ACmachine) | 1 | pole-pair number |
| Data | par (from AsynchronBase) | machine parameters | |
| Initialization | |||
| Types.Dynamics | dynType (from ACmachine) | system.dynType | transient or steady-state model |
| PS.Current | i_start (from ACmachine) | zeros(3) | start value of current conductor |
| SI.Angle | phi_el_start (from ACmachine) | 0 | initial rotor angle electric |
| PS.Current | i_d_start | zeros(n_r) | start value of current d_axis |
| PS.Current | i_q_start | zeros(n_r) | start value of current q_axis |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Ports.ACdq0_p | term (from Port_p) | positive terminal | |
| Interfaces.Rotation_n | airgap (from ACmachine) | electro-mechanical connection | |
| Interfaces.ThermalV_n | heat (from ACmachine) | heat source port {stator, rotor} | |
| Modelica.Blocks.Interfaces.RealOutput | i_meas | measured current {i_d, i_q} pu | |
| Modelica.Blocks.Interfaces.RealInput | i_act | actuated current {i_d, i_q} pu | |
| Modelica.Blocks.Interfaces.RealOutput | phiRotorflux | rotor-flux angle | |
| Modelica.Blocks.Interfaces.RealOutput | vPhasor | desired {abs(v), phase(v)} |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Topology_p | top (from YDport_p) | ||
| PS.Voltage | v (from YDport_p) | voltage conductor | |
| PS.Current | i (from YDport_p) | current conductor | |
| PS.Voltage | v_n (from YDport_p) | voltage neutral | |
| PS.Current | i_n (from YDport_p) | top.i_n | current neutral to ground |
| SI.Angle | phi_el (from ACmachine) | rotor angle electric (syn: +pi/2) | |
| SI.AngularVelocity | w_el (from ACmachine) | rotor angular velocity el | |
| SI.Torque | tau_el (from ACmachine) | electromagnetic torque | |
| Real | slip (from AsynchronBase) | <0: motor, >0: generator |
Contents
| Name | Description |
|---|---|
 acosprotected |