modelSynTransform
Rotation transform dq
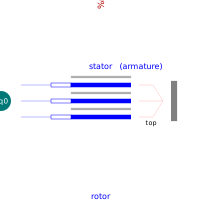
Extends from ACmachine (AC machine base, 3-phase dq0).
Information
Contains the transformation of stator voltage and current from the dq0 reference-frame to the dq0 rotor-frame.
The transformation angle is the (electric) rotor-angle relative to the reference frame.
If 'rotorSys = true', the reference frame is specified by the rotor. This allows to avoid the transformation. In this case, the system choice ('synchronous', 'inertial') has no influence. Note that this choice is not generally possible (for example several machines coupled to one common source).
v_s, i_s: stator-voltage and -current dq0 in the rotor frame of the machine.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Integer | pp (from ACmachine) | 1 | pole-pair number |
| Initialization | |||
| Types.Dynamics | dynType (from ACmachine) | system.dynType | transient or steady-state model |
| PS.Current | i_start (from ACmachine) | zeros(3) | start value of current conductor |
| SI.Angle | phi_el_start (from ACmachine) | 0 | initial rotor angle electric |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Ports.ACdq0_p | term (from Port_p) | positive terminal | |
| Interfaces.Rotation_n | airgap (from ACmachine) | electro-mechanical connection | |
| Interfaces.ThermalV_n | heat (from ACmachine) | heat source port {stator, rotor} |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Topology_p | top (from YDport_p) | ||
| PS.Voltage | v (from YDport_p) | voltage conductor | |
| PS.Current | i (from YDport_p) | current conductor | |
| PS.Voltage | v_n (from YDport_p) | voltage neutral | |
| PS.Current | i_n (from YDport_p) | top.i_n | current neutral to ground |
| SI.Angle | phi_el (from ACmachine) | rotor angle electric (syn: +pi/2) | |
| SI.AngularVelocity | w_el (from ACmachine) | rotor angular velocity el | |
| SI.Torque | tau_el (from ACmachine) | electromagnetic torque | |
| PS.Voltage | v_s | stator voltage dq0 in rotor-system | |
| PS.Current | i_s | stator current dq0 in rotor-system |