modelBeBot_SW_Main

Information

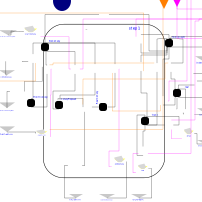
The interface of the class BeBot_SW defines three incoming parameters: the distance to a BeBot that drives in front, the cruisingSpeed of the BeBot, and bebotStop that defines if the BeBot has to stop. The outgoing parameter is the speed of the BeBot. Furthermore five asynchronous messages are defined that can be sent and received: StartPlatoon to propose to start a platoon, Con?rm to confirm the start proposal, EndPlatoon to command the end of the platoon, Stop to command a rear-driving BeBot to stop, and Drive to inform a rear-driving BeBot that it no longer has to stop.

Within BeBot_SW two parallel branches were defined. The first branch handles the platoon activation and deactivation and consists of the steps NoPlatoon, PlatoonProposed, and FrontPlatoon; the second branch handles the coordinated braking within a platoon and consists of the steps Regular (a BeBot has no limita- tions regarding braking), Front (a BeBot has first to inform the rear-driving BeBot before braking), and Rear (a BeBot must brake when the front-driving BeBot commands it). The synchronization between the two branches is realized by using synchronous messages, e.g. if step FrontPlatoon is activated, then step Front will also be activated at the same time. Among others, this class contains a timing constraint that the state PlatoonProposed is no longer active than 50ms.

Parameters

TypeNameDefaultDescription
Booleansync_visiblefalse

Connectors

TypeNameDefaultDescription
RealTimeCoordinationLibrary.MessageInterface.DelegationPortInStartConvoyDel
Modelica_StateGraph2.Blocks.Interfaces.RealVectorInputfrontDistance
RealTimeCoordinationLibrary.MessageInterface.DelegationPortOutStartConvoyDel
RealTimeCoordinationLibrary.MessageInterface.DelegationPortOutConfirm
RealTimeCoordinationLibrary.MessageInterface.DelegationPortInConfirm
RealTimeCoordinationLibrary.MessageInterface.DelegationPortoutEndConvoy
RealTimeCoordinationLibrary.MessageInterface.DelegationPortinEndConvoy
Modelica.Blocks.Interfaces.BooleanInputstop
Modelica.Blocks.Interfaces.RealOutputspeed
RealTimeCoordinationLibrary.MessageInterface.DelegationPortoutHalt
RealTimeCoordinationLibrary.MessageInterface.DelegationPortInHalt
Modelica.Blocks.Interfaces.IntegerInputcruisingSpeed
RealTimeCoordinationLibrary.MessageInterface.DelegationPortoutDrive
RealTimeCoordinationLibrary.MessageInterface.DelegationPortinDrive1

Components

TypeNameDefaultDescription
Modelica_StateGraph2.StepNoConvoy
Modelica_StateGraph2.Parallelstep1
Modelica_StateGraph2.StepNoConvoyV
RealTimeCoordinationLibrary.StepFrontConvoy
RealTimeCoordinationLibrary.TransitionT2
RealTimeCoordinationLibrary.MailboxstartConvBox
RealTimeCoordinationLibrary.TransitionT1
RealTimeCoordinationLibrary.StepConvoyProposed
RealTimeCoordinationLibrary.MessagestartConvoy
Modelica_StateGraph2.Stepfront
RealTimeCoordinationLibrary.TransitionT3
RealTimeCoordinationLibrary.TransitionT4
RealTimeCoordinationLibrary.Steprear
RealTimeCoordinationLibrary.TransitionT5
RealTimeCoordinationLibrary.StepRearConvoy
RealTimeCoordinationLibrary.TransitionT6
RealTimeCoordinationLibrary.Messageconfirm
RealTimeCoordinationLibrary.MailboxconfirmBox
RealTimeCoordinationLibrary.TransitionT7
RealTimeCoordinationLibrary.MessageendConvoy
RealTimeCoordinationLibrary.TransitionT8
RealTimeCoordinationLibrary.MailboxendConvoyBox
RealTimeCoordinationLibrary.TransitionT9
RealTimeCoordinationLibrary.TransitionT10
RealTimeCoordinationLibrary.SelfTransitionT11
RealTimeCoordinationLibrary.Messagehalt
RealTimeCoordinationLibrary.MailboxhaltBox
RealTimeCoordinationLibrary.SelfTransitionT12
RealTimeCoordinationLibrary.SelfTransitionT13
RealTimeCoordinationLibrary.SelfTransitionT14
Modelica.Blocks.MathBoolean.Notnor1
RealTimeCoordinationLibrary.SelfTransitionT15
RealTimeCoordinationLibrary.Messagedrive
RealTimeCoordinationLibrary.MailboxdriveBox
RealTimeCoordinationLibrary.SelfTransitionT16