modelRRTorqueAnalysis
Extends from Modelica.Icons.Example (Icon for runnable examples), Servomechanisms.Examples.RRServomechanism.Data (RR Servomechanism Data).
Information
General
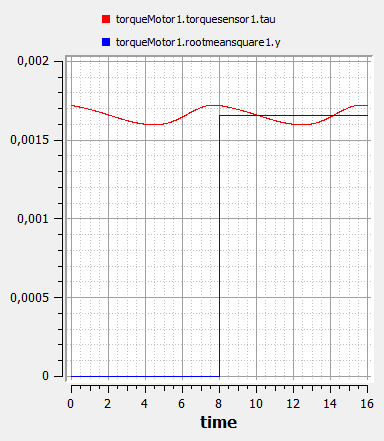
With this model the torque and RMS torque on each joint can be analysed. With this configuration the dynamic of the system can be calculated.
Implementation
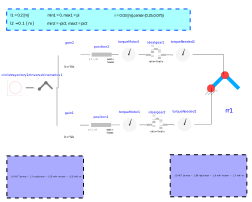
The block of the trayectory is used as input. The outputs of this block are connected to the inputs of the block of inverse kinematics. In this way the coordinates of the trayectory are transform into joint variables.
Utilizing the position source the mechanisms will follow the trayectory and with the acausal modelling it is possible to obtain the torque needed in each joint. If a reduction is used, then the joint variables should be multiplied with the parameter ratio of the idealgear block in order to obtain the expected result.
Notes
- The velocities obtain are equivalent to calculate differential fordward kinematics
- The results in this simulations are equivalent to obtain the dynamical behaviour of the systems with methods as Euler Lagrange Equations or Newton-Euler Equations.
-
The analysis of torques and velocities allow the selection of the actuator (dc motor) following the next criteria (although it should be taken into account the effects of disturbances):
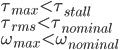
- In order to evaluate the rms torque the simulation should run for two cycles
- Note that there are two torque analysis (or force analysis) elements per joint, one to evaluate the needed values for the mechanisms and other for those that the motor would proportionate if a reduction is added.
Example
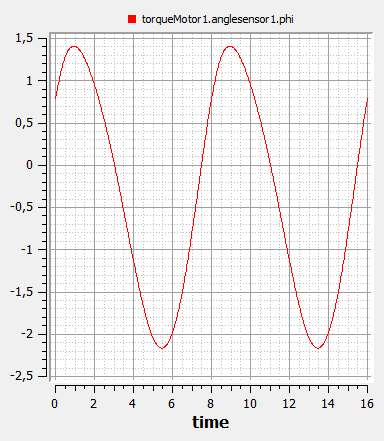
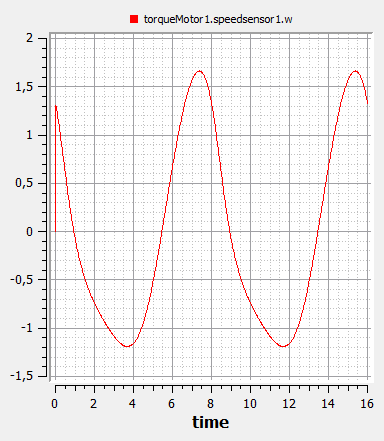
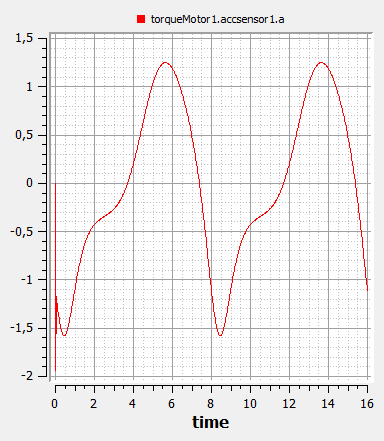
For the first joint:
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Real | l1 (from Data) | 0.2 | |
| Real | w1 (from Data) | 0.02 | |
| Real | h1 (from Data) | 0.005 | |
| Real | d1 (from Data) | 400 | |
| Real | min1 (from Data) | 0 | |
| Real | max1 (from Data) | pi/2 | |
| Real | l2 (from Data) | 0.1 | |
| Real | w2 (from Data) | 0.02 | |
| Real | h2 (from Data) | 0.005 | |
| Real | d2 (from Data) | 400 | |
| Real | min2 (from Data) | -pi/2 | |
| Real | max2 (from Data) | pi/2 | |
| Real | r (from Data) | 0.03 | |
| Real | xc (from Data) | 0.25 | |
| Real | yc (from Data) | 0.075 | |
| Real | ratio1 (from Data) | 10 | |
| Real | ratio2 (from Data) | 5 | |
| Real | period (from Data) | 8 | |
| Real | R (from Data) | 0.101 | |
| Real | L (from Data) | 0.0000266 | |
| Real | k (from Data) | 0.0115 | |
| Real | J (from Data) | 0.0000119 | |
| Real | Voltage (from Data) | 12 | |
| Real | kp2 (from Data) | 4.423 | |
| Real | kp1 (from Data) | 7.1543 |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Servomechanisms.Control.CircleTrayectory | circletrayectory1 | ||
| Servomechanisms.Control.RRInverseKinematics | rrinversekinematics1 | ||
| Modelica.Blocks.Math.Gain | gain2 | ||
| Modelica.Blocks.Math.Gain | gain1 | ||
| Modelica.Mechanics.Rotational.Sources.Position | position2 | ||
| Modelica.Mechanics.Rotational.Sources.Position | position1 | ||
| Servomechanisms.Mechanism.TorqueAnalysis | torqueMotor1 | ||
| Servomechanisms.Mechanism.TorqueAnalysis | torqueMotor2 | ||
| Modelica.Mechanics.Rotational.Components.IdealGear | idealgear2 | ||
| Modelica.Mechanics.Rotational.Components.IdealGear | idealgear1 | ||
| Servomechanisms.Mechanism.TorqueAnalysis | torqueNeeded1 | ||
| Servomechanisms.Mechanism.TorqueAnalysis | torqueNeeded2 | ||
| Servomechanisms.Mechanism.RR | rr1 |